Reporting library

Systems, components, and the work between them.

The library is deliberately focused: maintained guides grounded in current primary or authoritative sources.

60 maintained articles / 6 connected beats

Unbranded telemetry radio and coiled cable beside a dark-screen laptop and propeller-free drone on a workshop bench.Photo: Publication editorial image

Does MAVLink 2 Signing Encrypt Drone Data? Authentication and Confidentiality Explained

MAVLink signing authenticates messages without encryption. Understand replay protection, PX4 and ArduPilot differences, and transport and endpoint requirements.

Owner-authorized original generated editorial asset through the existing approved account; no third-party reference image or exact-product likeness.

Read the analysis
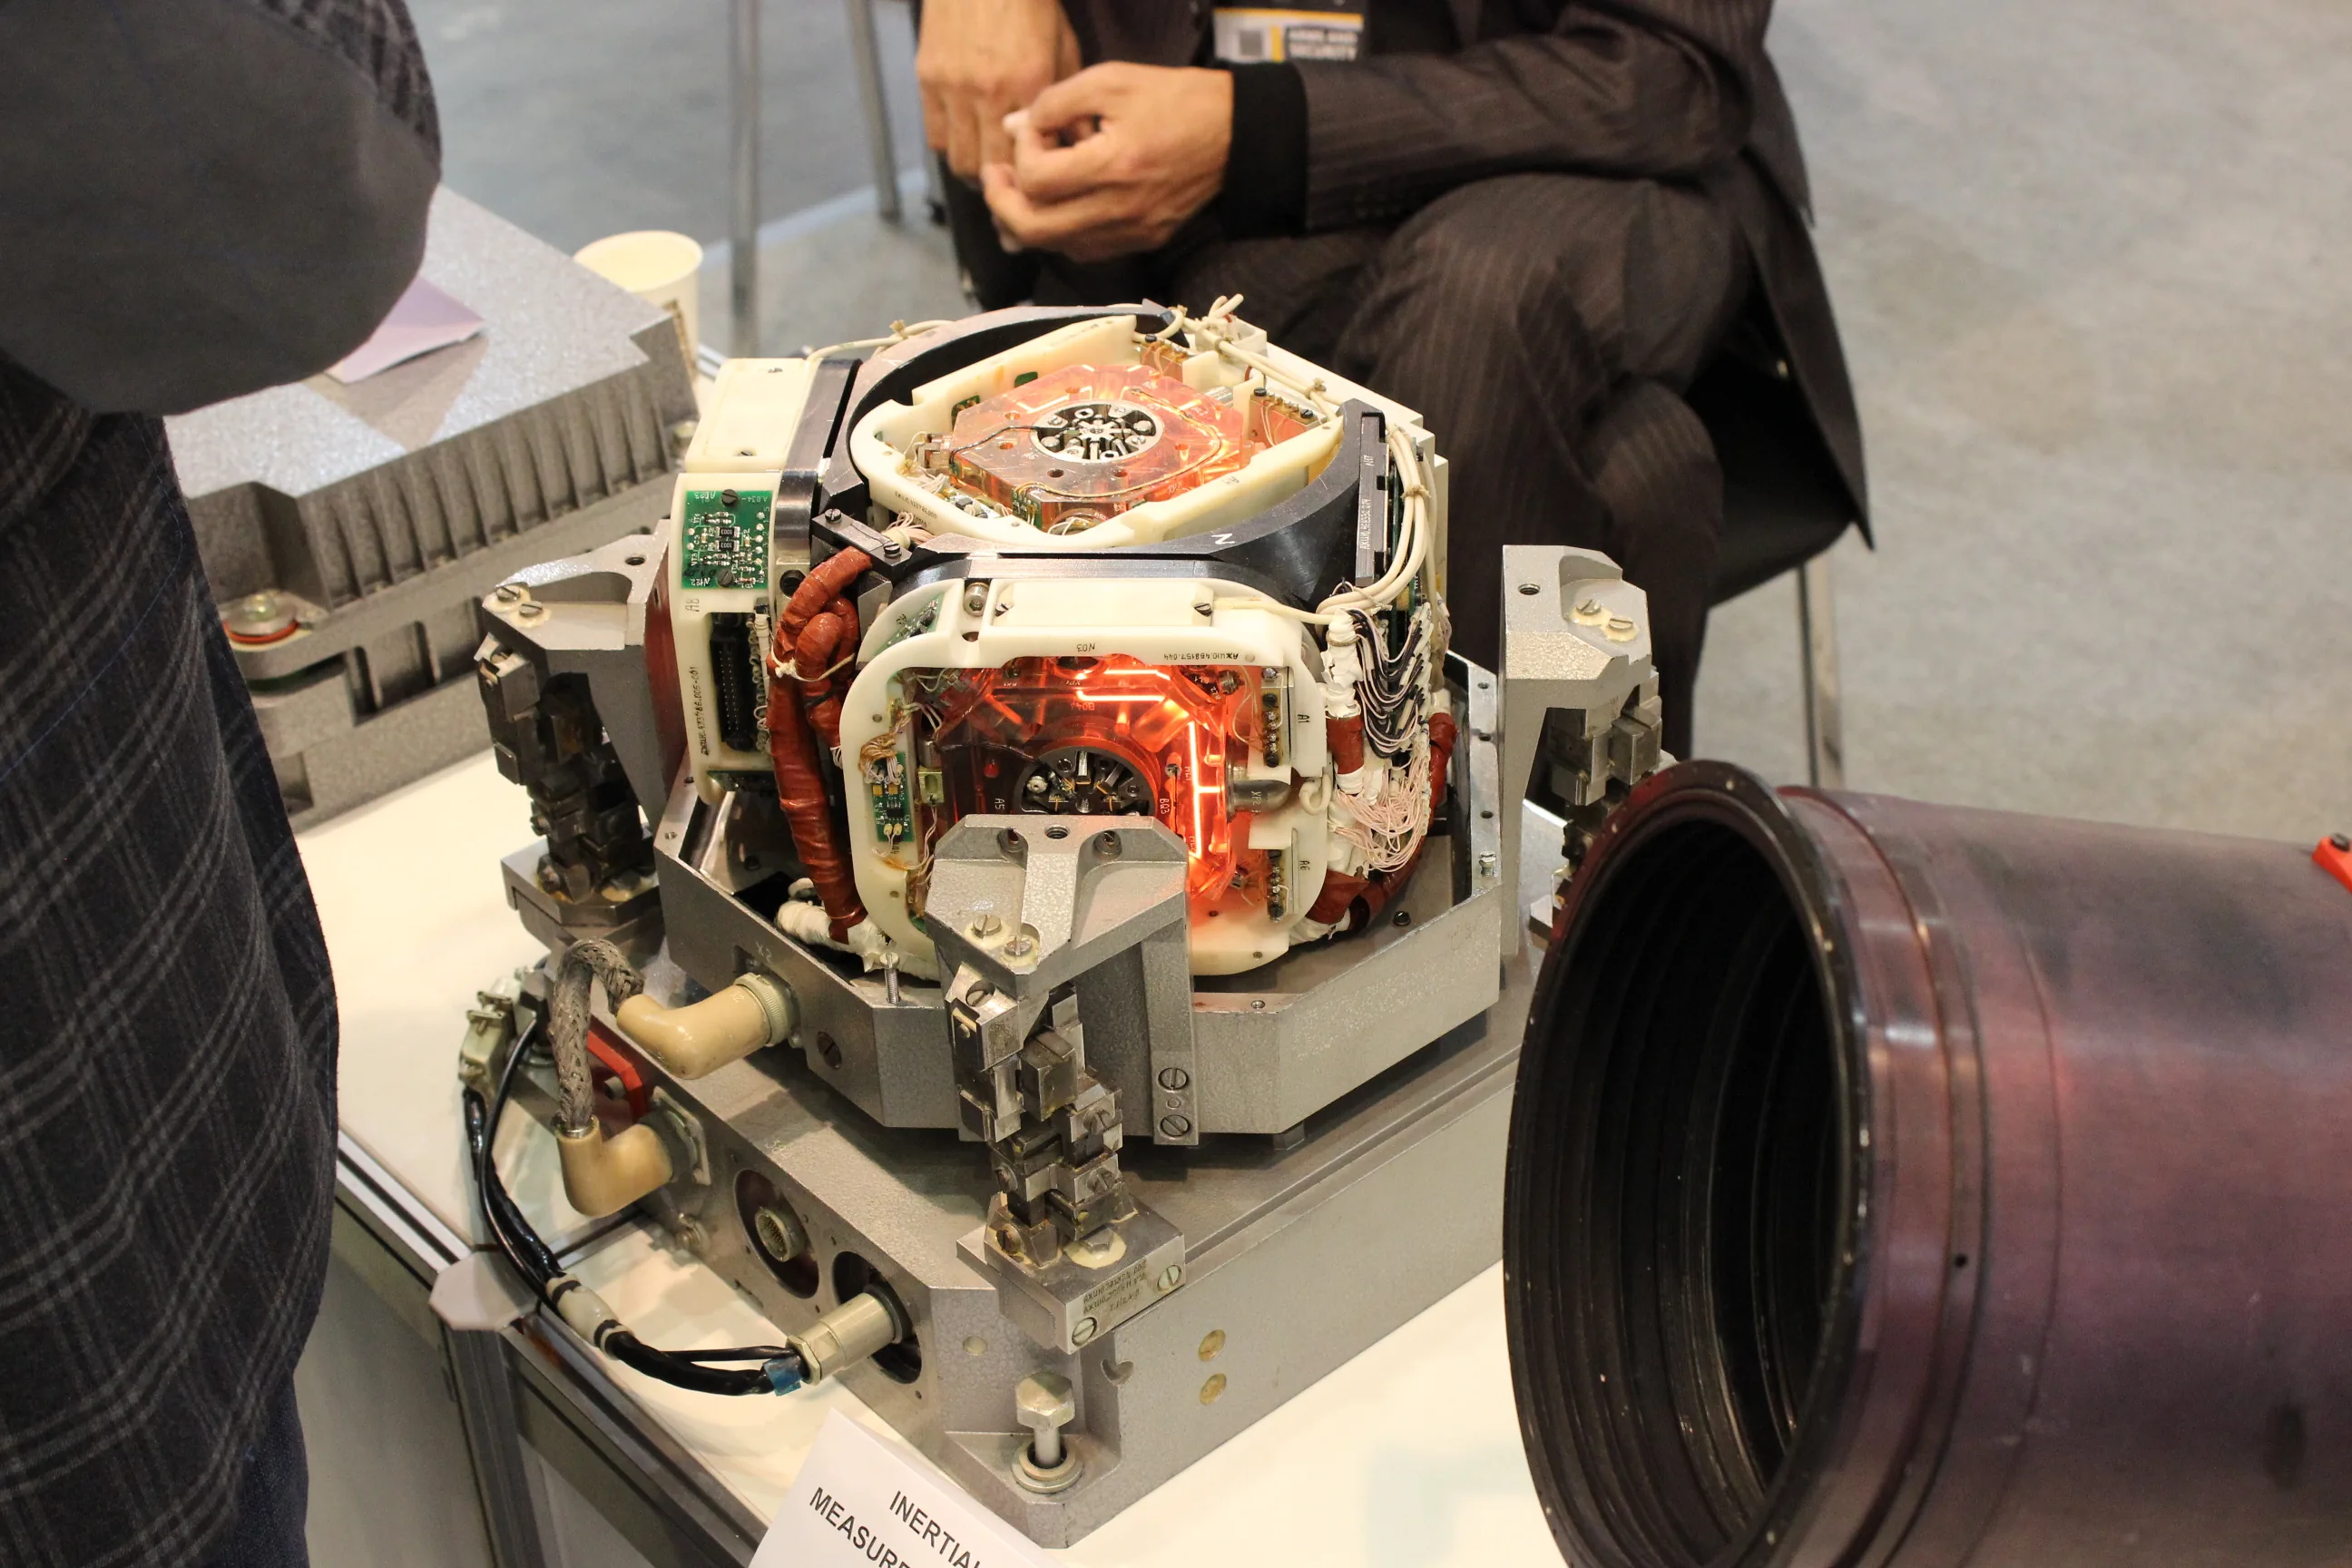
Exposed IMU-28 assembly with orange sensor elements, wiring, circuit boards, and metal mounting supports.Photo: VictorAnyakin / Wikimedia Commons / CC BY-SA 4.0 (https://creativecommons.org/licenses/by-sa/4.0/). Unmodified.

IMU Error, Drift, and Calibration

Understand IMU drift, bias, noise, calibration, temperature compensation, timing errors, and the checks that connect sensor performance to navigation accuracy.

Creative Commons Attribution-ShareAlike 4.0 International; https://creativecommons.org/licenses/by-sa/4.0/; original photographer license on Wikimedia Commons file record.

Read the analysis
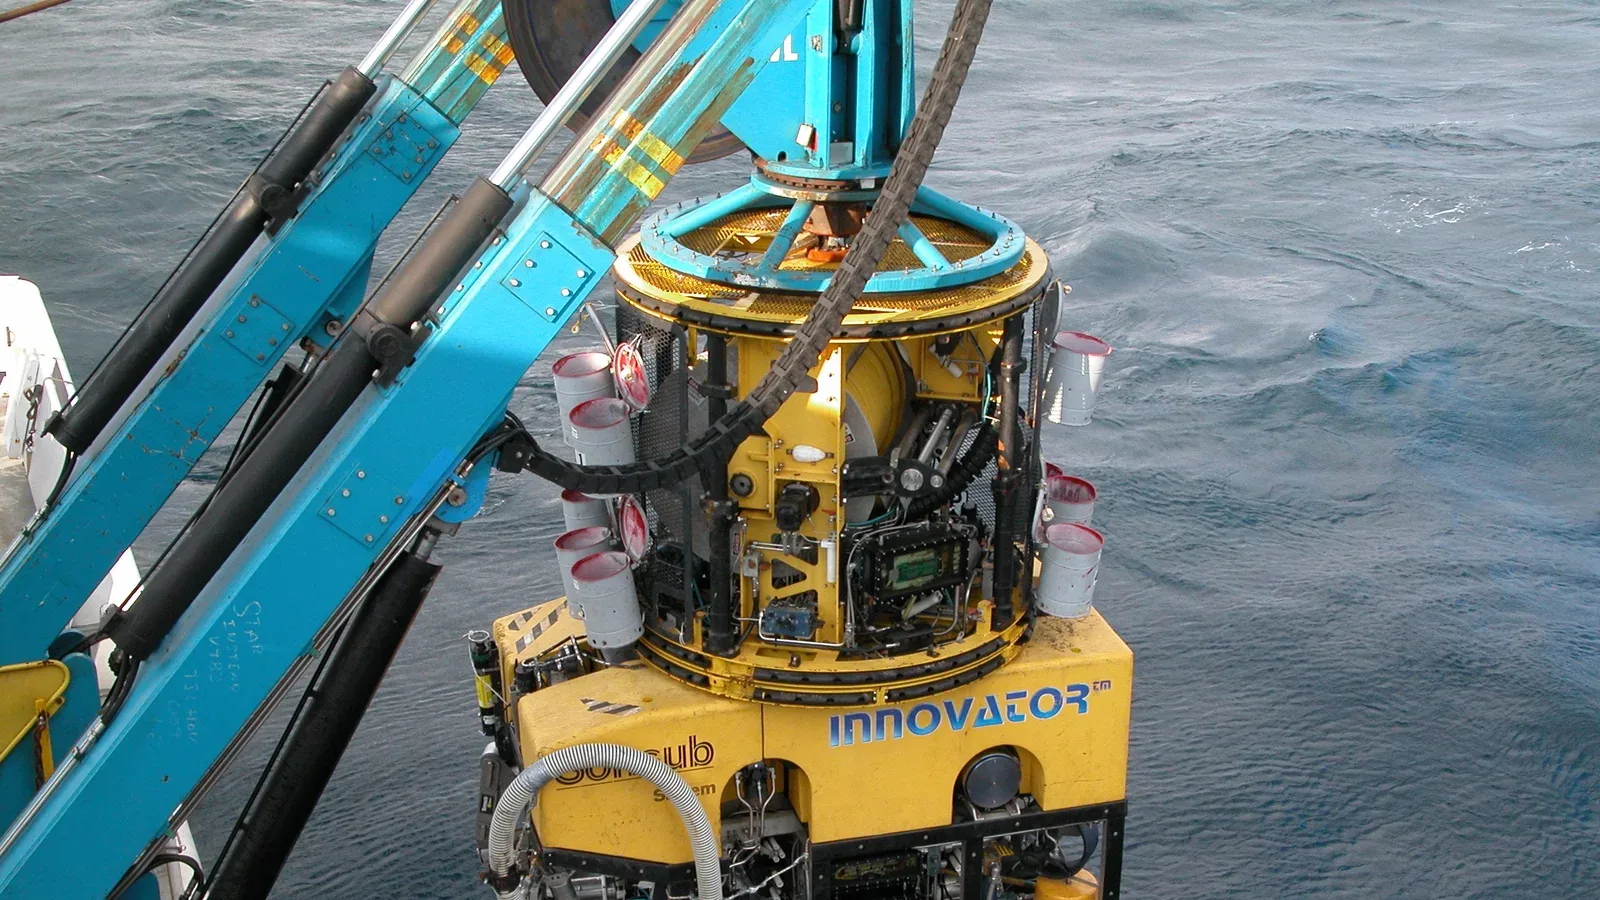
A cylindrical tether management assembly sits above a yellow remotely operated vehicle suspended beside a vessel over the sea.Photo: Gulf of Mexico Deep Sea Habitats Expedition/NOAA/OAR/OER. CC BY 2.0: https://creativecommons.org/licenses/by/2.0/

ROV Tether Management Systems

Understand ROV tether management architecture, top-hat and garage layouts, control interfaces, excursion limits, failure modes, and recovery requirements.

The NOAA Photo Library source explicitly links this photograph to Creative Commons Attribution 2.0, which permits sharing and adaptation including commercial reuse with credit, a license URI and indication of changes.

Read the analysis
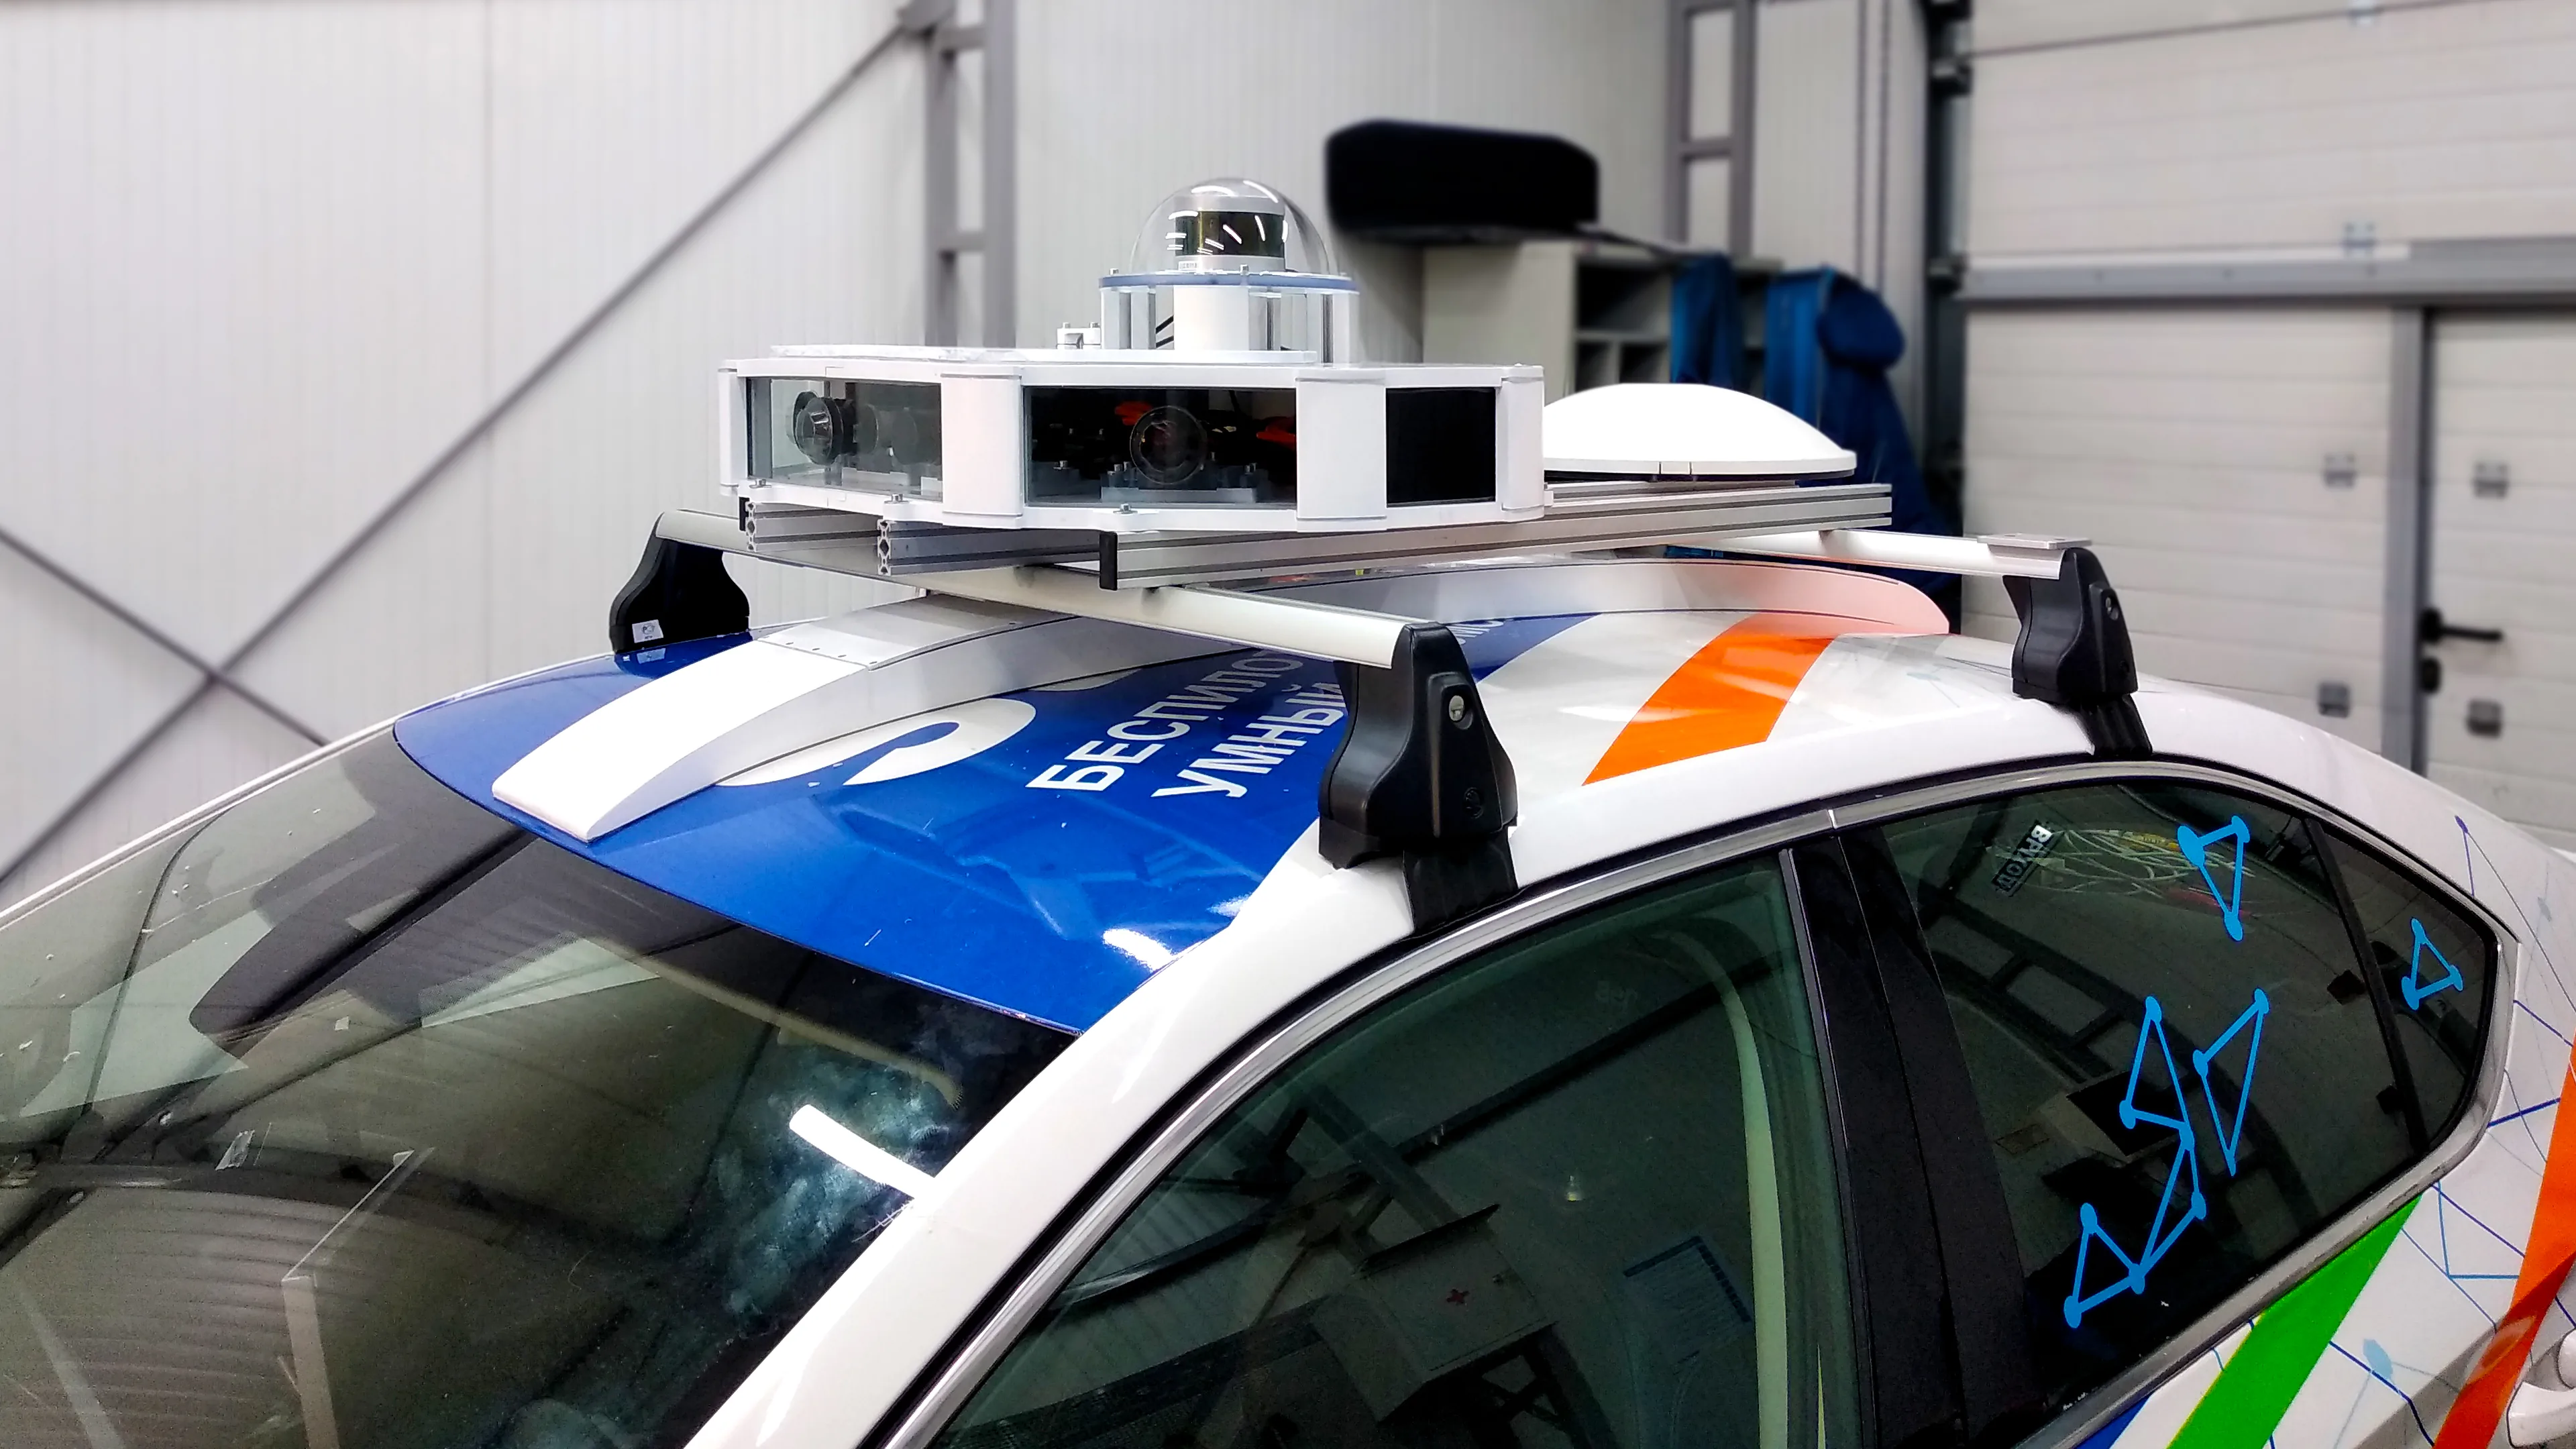
Roof-mounted camera housings, a laser scanner, and navigation equipment on a vehicle inside a workshopPhoto: Alena Nesterova / Wikimedia Commons; CC BY-SA 4.0: https://creativecommons.org/licenses/by-sa/4.0/; unchanged.

Radar vs LiDAR vs Cameras for Autonomous Vehicles

Compare radar, LiDAR, and cameras for autonomous vehicles: measurement principles, weather limits, calibration, timing, integration, and mission fit.

Creative Commons Attribution-ShareAlike 4.0 International, stated by the author on the Wikimedia Commons source page. https://creativecommons.org/licenses/by-sa/4.0/

Read the analysis
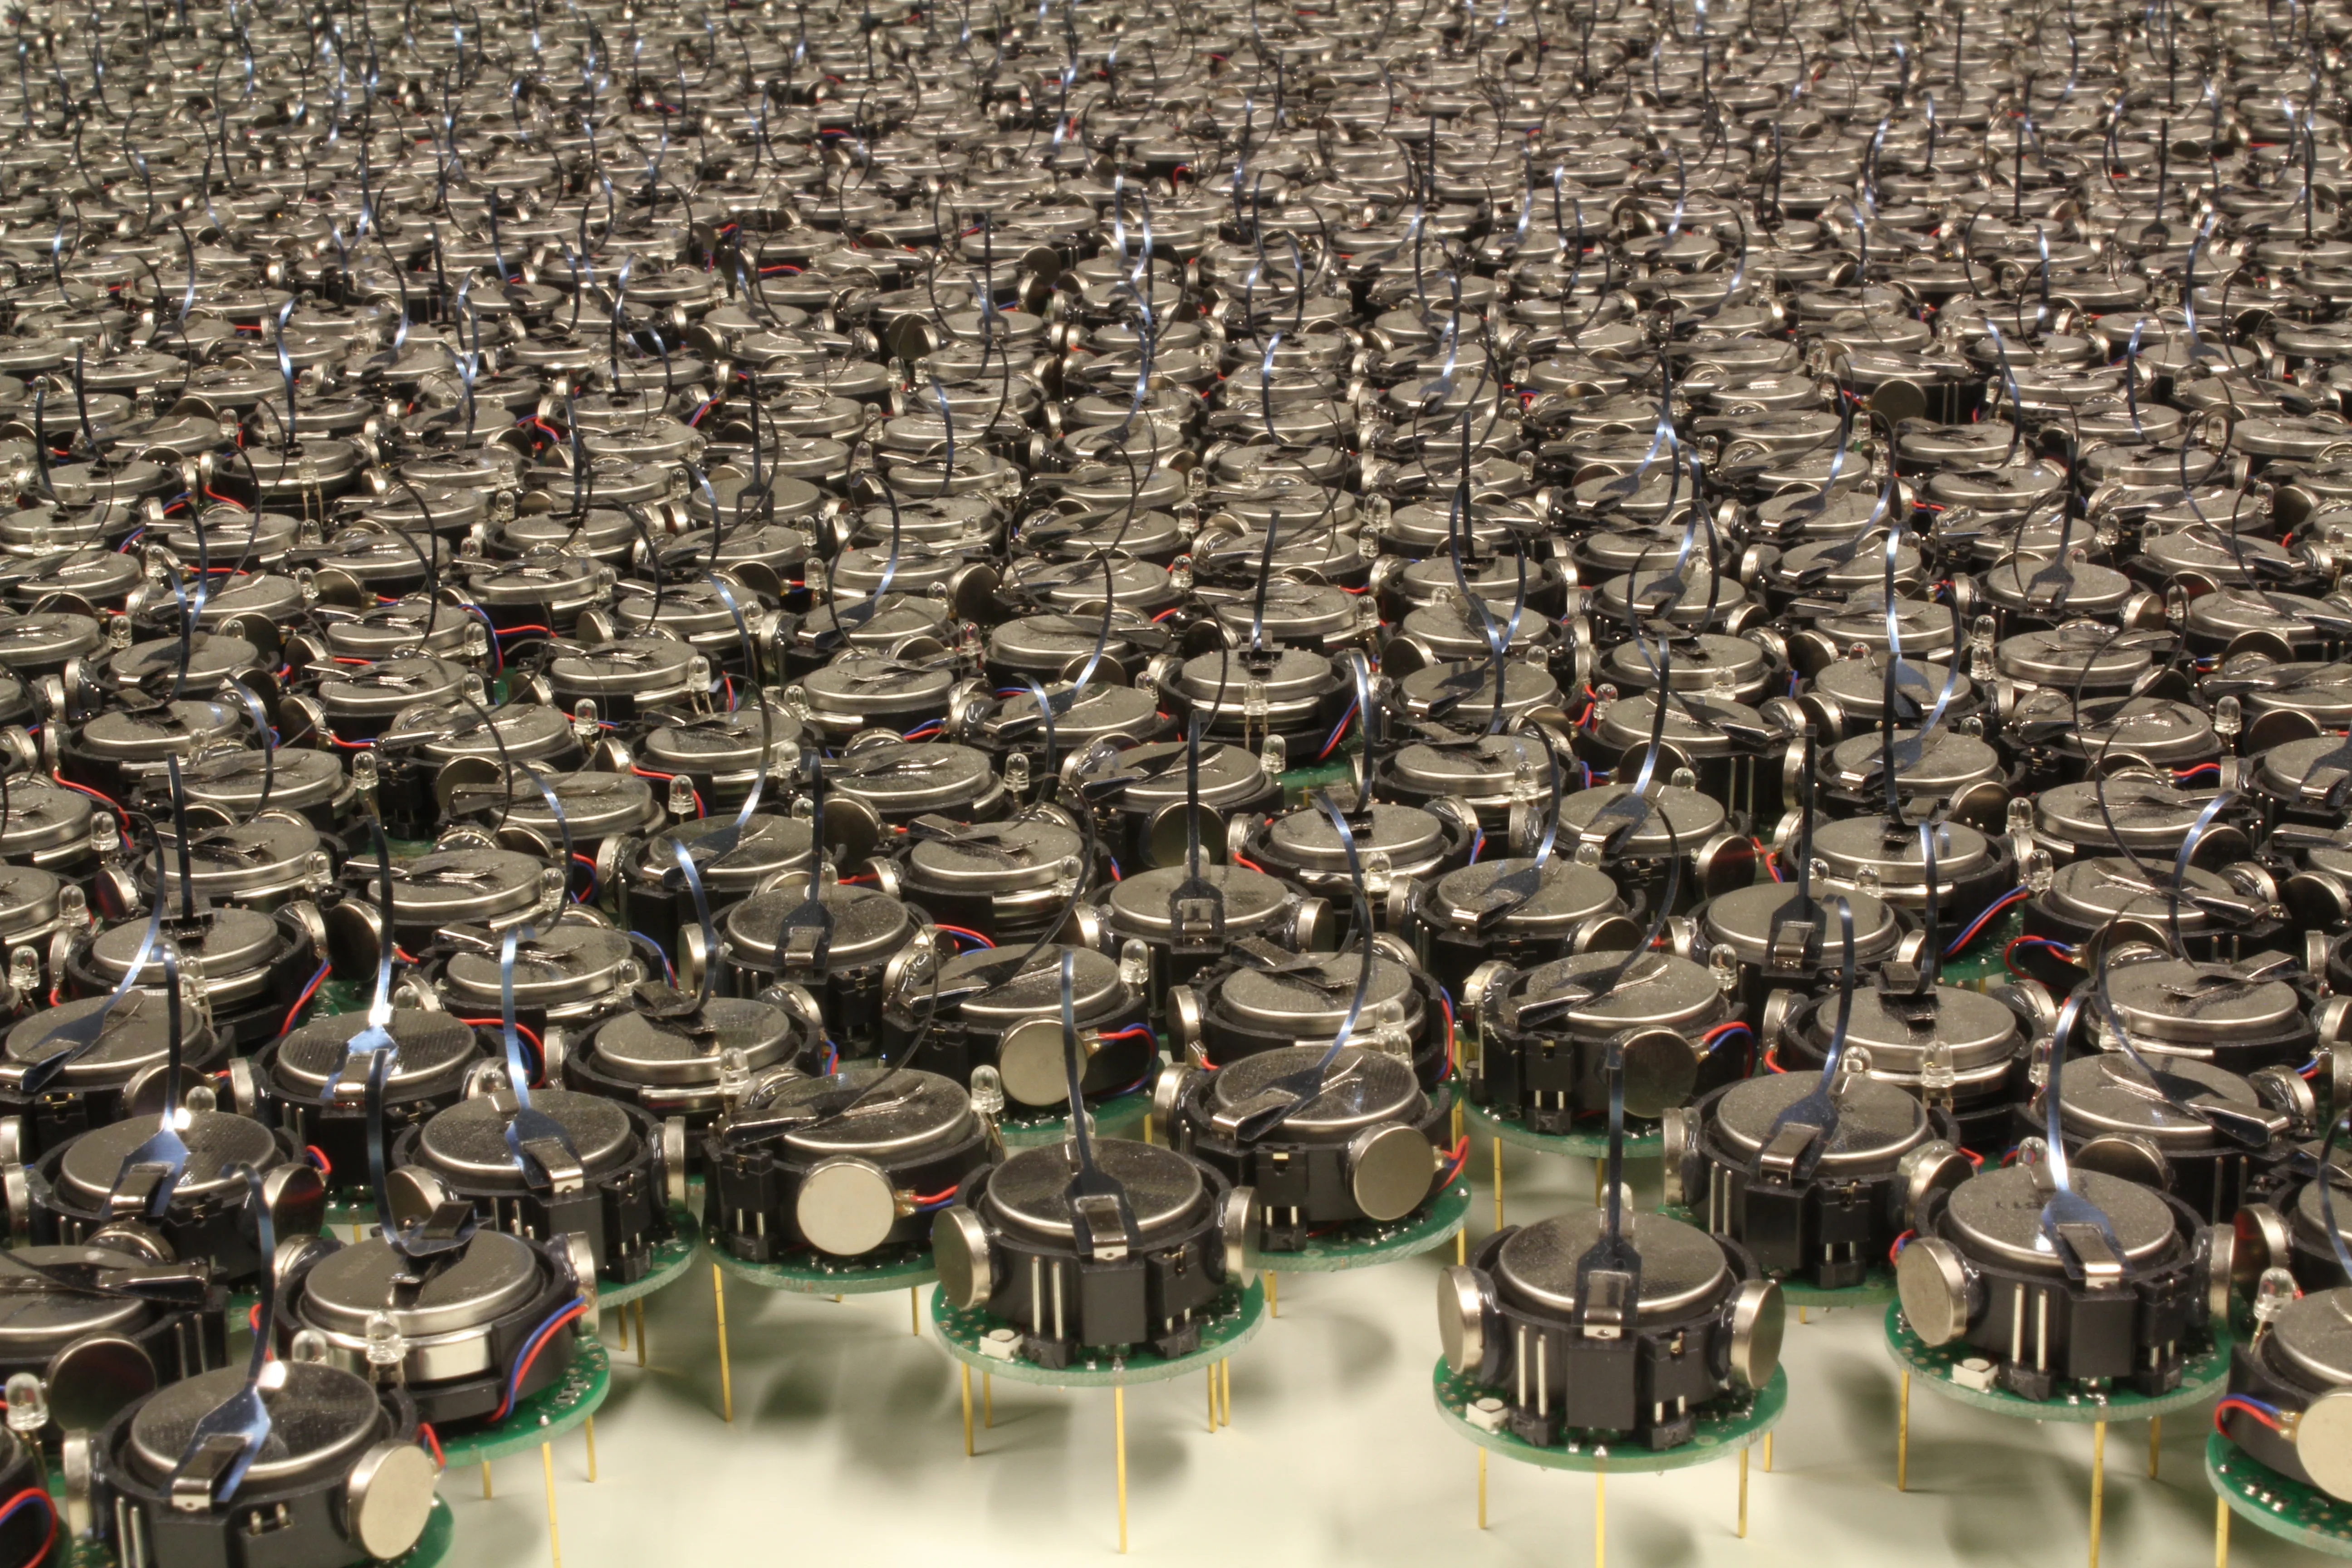
Rows of small Kilobot robots on a white surface, with round batteries, exposed circuit boards, and slender metal legs.Photo: asuscreative / Wikimedia Commons. CC BY-SA 4.0: https://creativecommons.org/licenses/by-sa/4.0/. Unchanged.

Swarm Robotics: Coordination Without a Central Controller

Learn how robot swarms coordinate through local decisions, which interfaces and shared services they need, and how scale and failures affect collective behavior.

The creator's own-work file page explicitly licenses this photograph under Creative Commons Attribution-ShareAlike 4.0 International: https://creativecommons.org/licenses/by-sa/4.0/.

Read the analysis
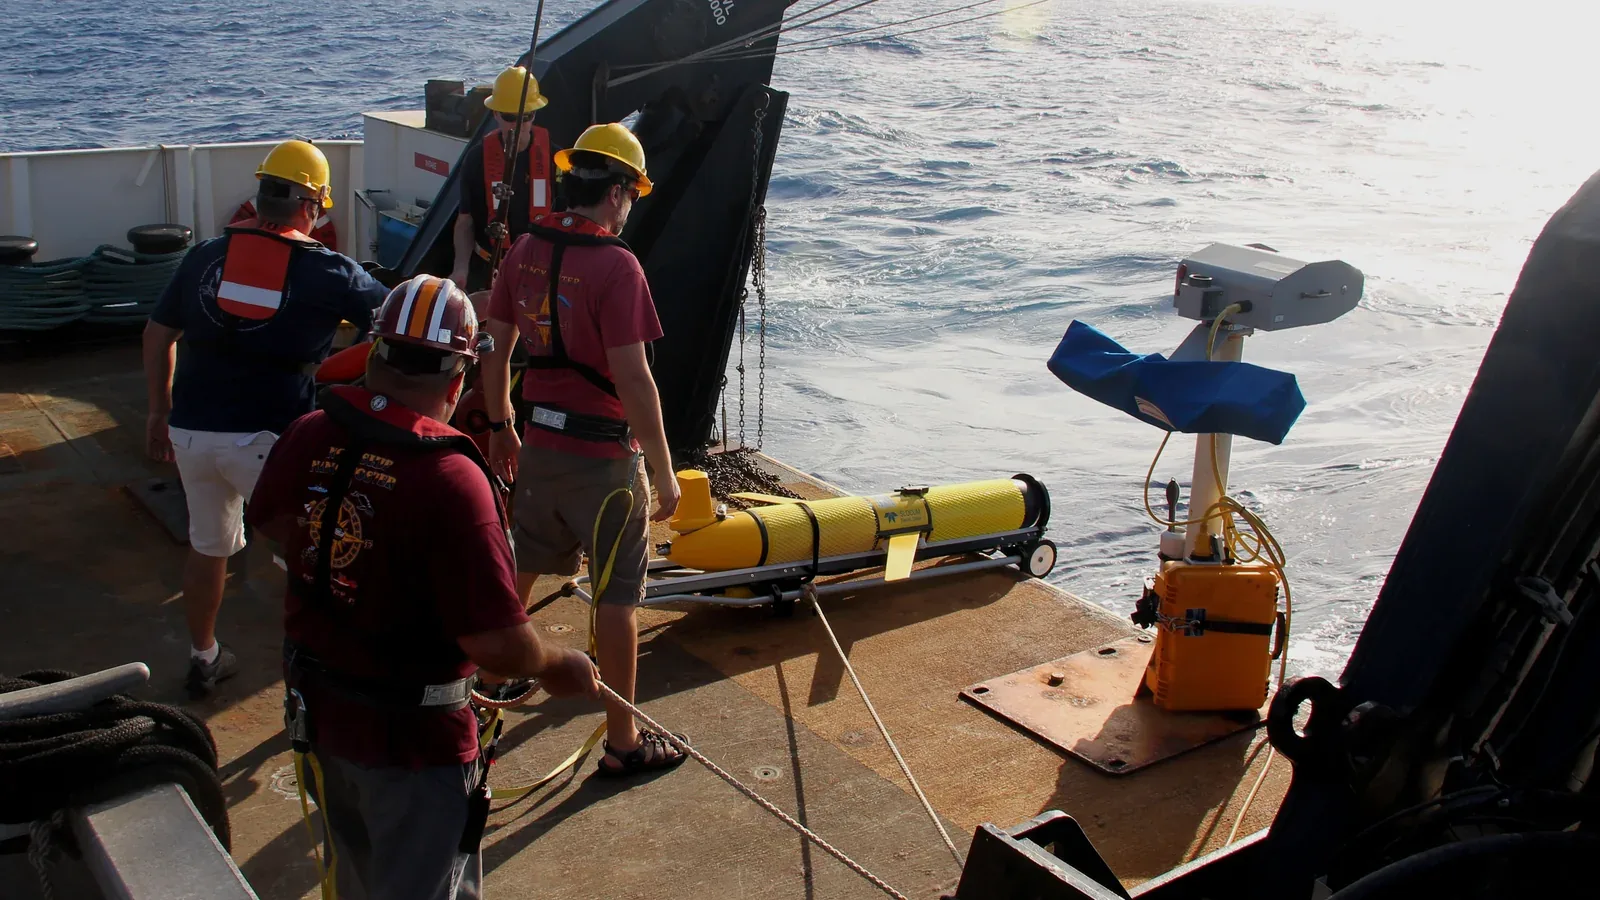
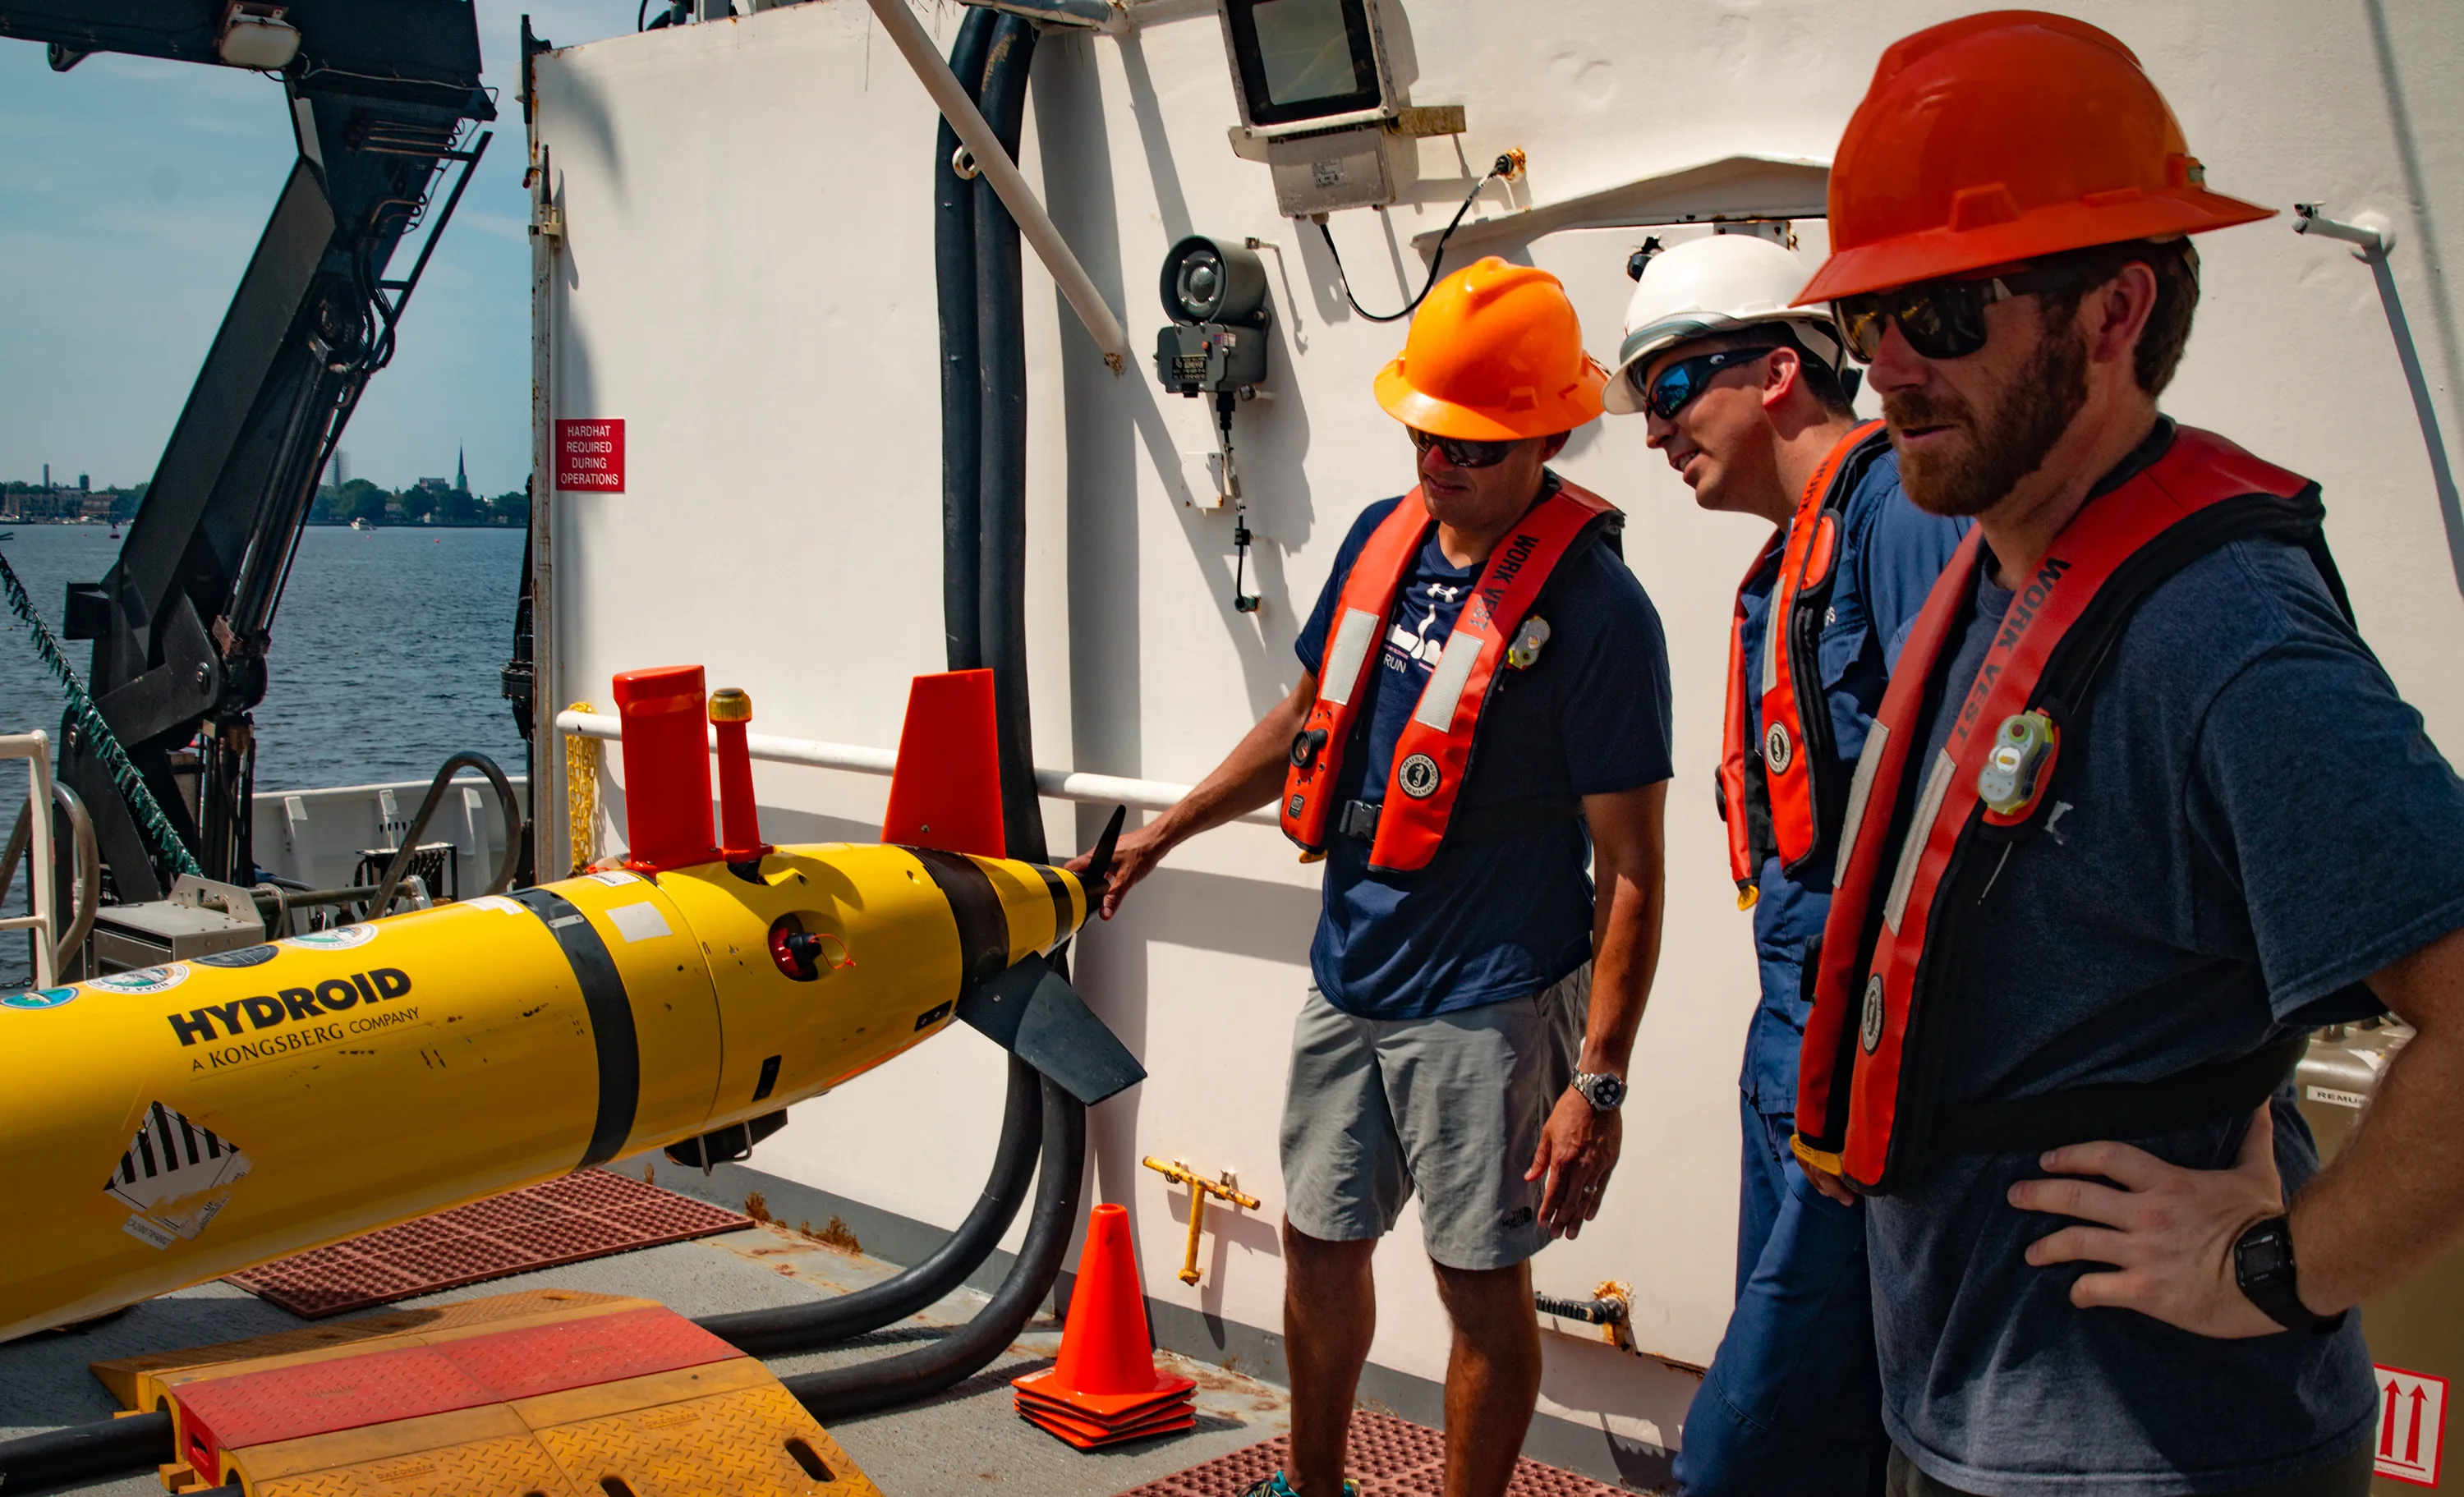
Three NOAA personnel stand beside a yellow REMUS 600 autonomous underwater vehicle on a ship deck.Photo: NOAA Office of Ocean Exploration and Research, 2019 Technology Demonstration

Acoustic Communications for Underwater Vehicles

How underwater acoustic communication works, including modem architecture, latency, interfaces, JANUS interoperability, failure diagnosis, and AUV applications.

Public domain under NOAA Ocean Exploration policy: https://oceanexplorer.noaa.gov/faqs/. No copyright exception noted. Retain image credit and embedded metadata.

Read the analysis
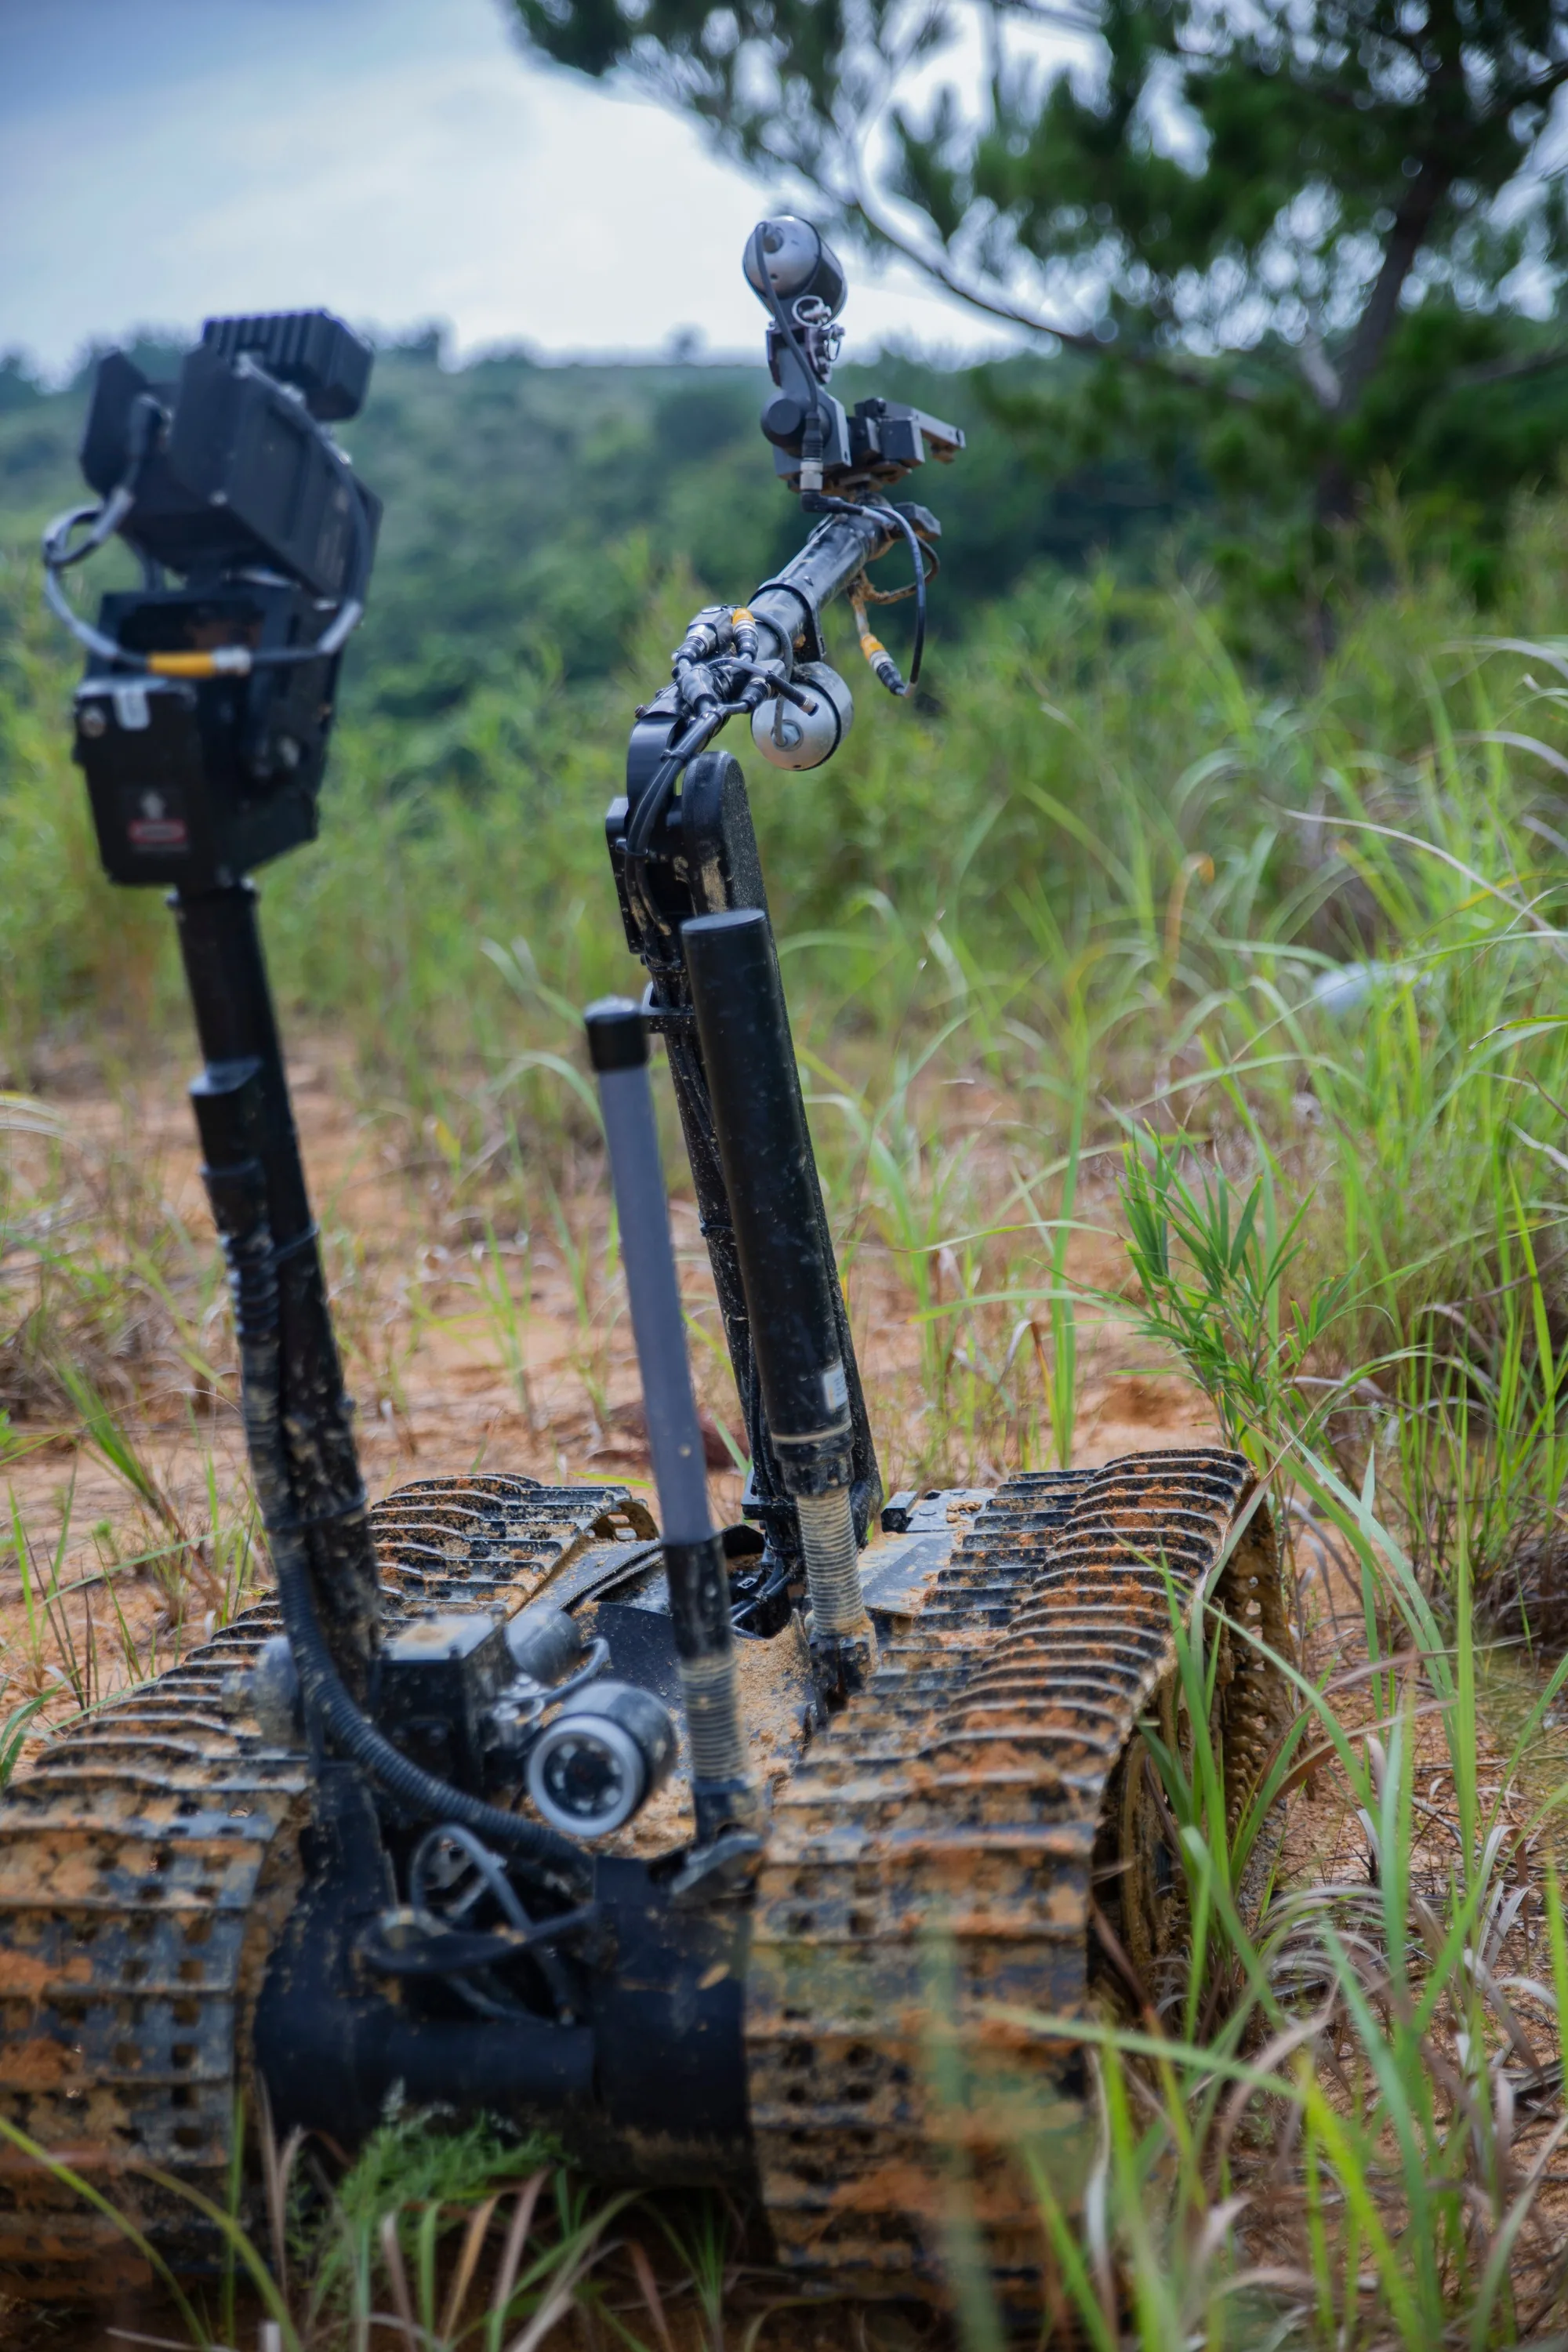
Tracked EOD robot on a grassy path with an extended articulated arm, gripper, and several camera housings.Photo: U.S. Marine Corps photo by Pfc. Terry Wong, via DVIDS. Public domain.

EOD Robots: Manipulators, Cameras, and Operator Control

How EOD robot arms, cameras, and operator controls work together, with reach tradeoffs, interfaces, communication limits, and failure-mode evaluation.

The DVIDS record explicitly marks image 4612123 PUBLIC DOMAIN and credits a U.S. Marine Corps official-duty photograph. Reuse follows https://www.dvidshub.net/about/copyright.

Read the analysis
Ion Tiger aircraft nose and separate components on a laboratory bench during an NRL demonstration to visitors in 2012.Photo: John Williams / U.S. Navy, via DVIDS. Public-domain photograph.

Hydrogen Fuel Cells for Long-Endurance Drones

How hydrogen fuel cell drones work, from PEM stacks and storage tanks to power interfaces, battery reserves, failure modes, and realistic endurance.

Public-domain U.S. Navy image, DVIDS 543710. Historical editorial use under https://www.dvidshub.net/about/copyright; credit and required non-endorsement notice retained.

Read the analysis
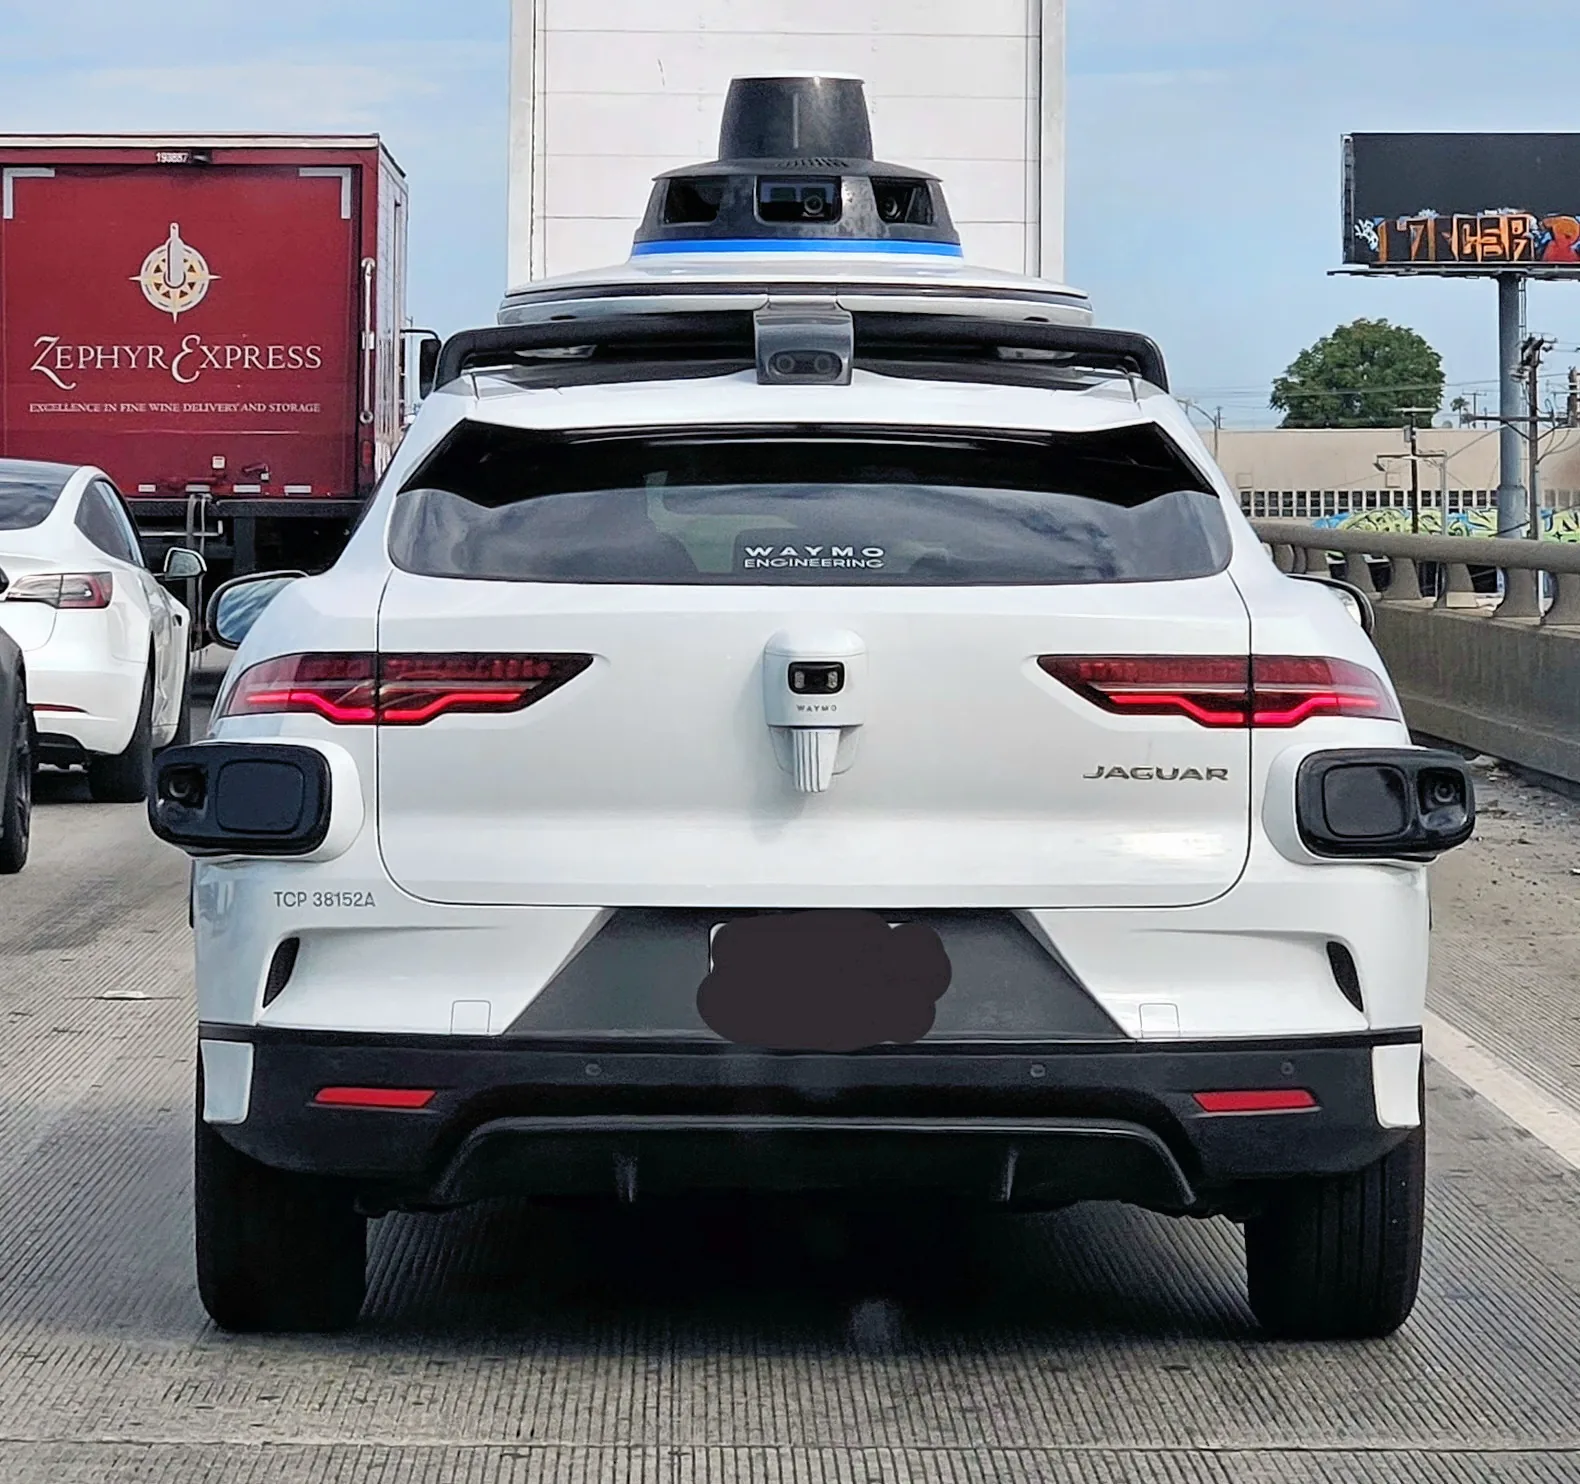
Rear view of a white Waymo Jaguar in road traffic, with roof-mounted sensors and additional rear sensor housings.Photo: Eric Polk / Wikimedia Commons / CC BY-SA 4.0: https://creativecommons.org/licenses/by-sa/4.0/

Levels of Vehicle Autonomy Explained

Understand vehicle autonomy Levels 0 to 5, driver responsibilities, operating domains, system architecture, and fallback questions for comparing features.

Eric Polk own-work photograph, CC BY-SA 4.0 on the exact Commons file page. Commercial reuse and adaptations allowed with attribution, license link, change notice, and ShareAlike.

Read the analysis
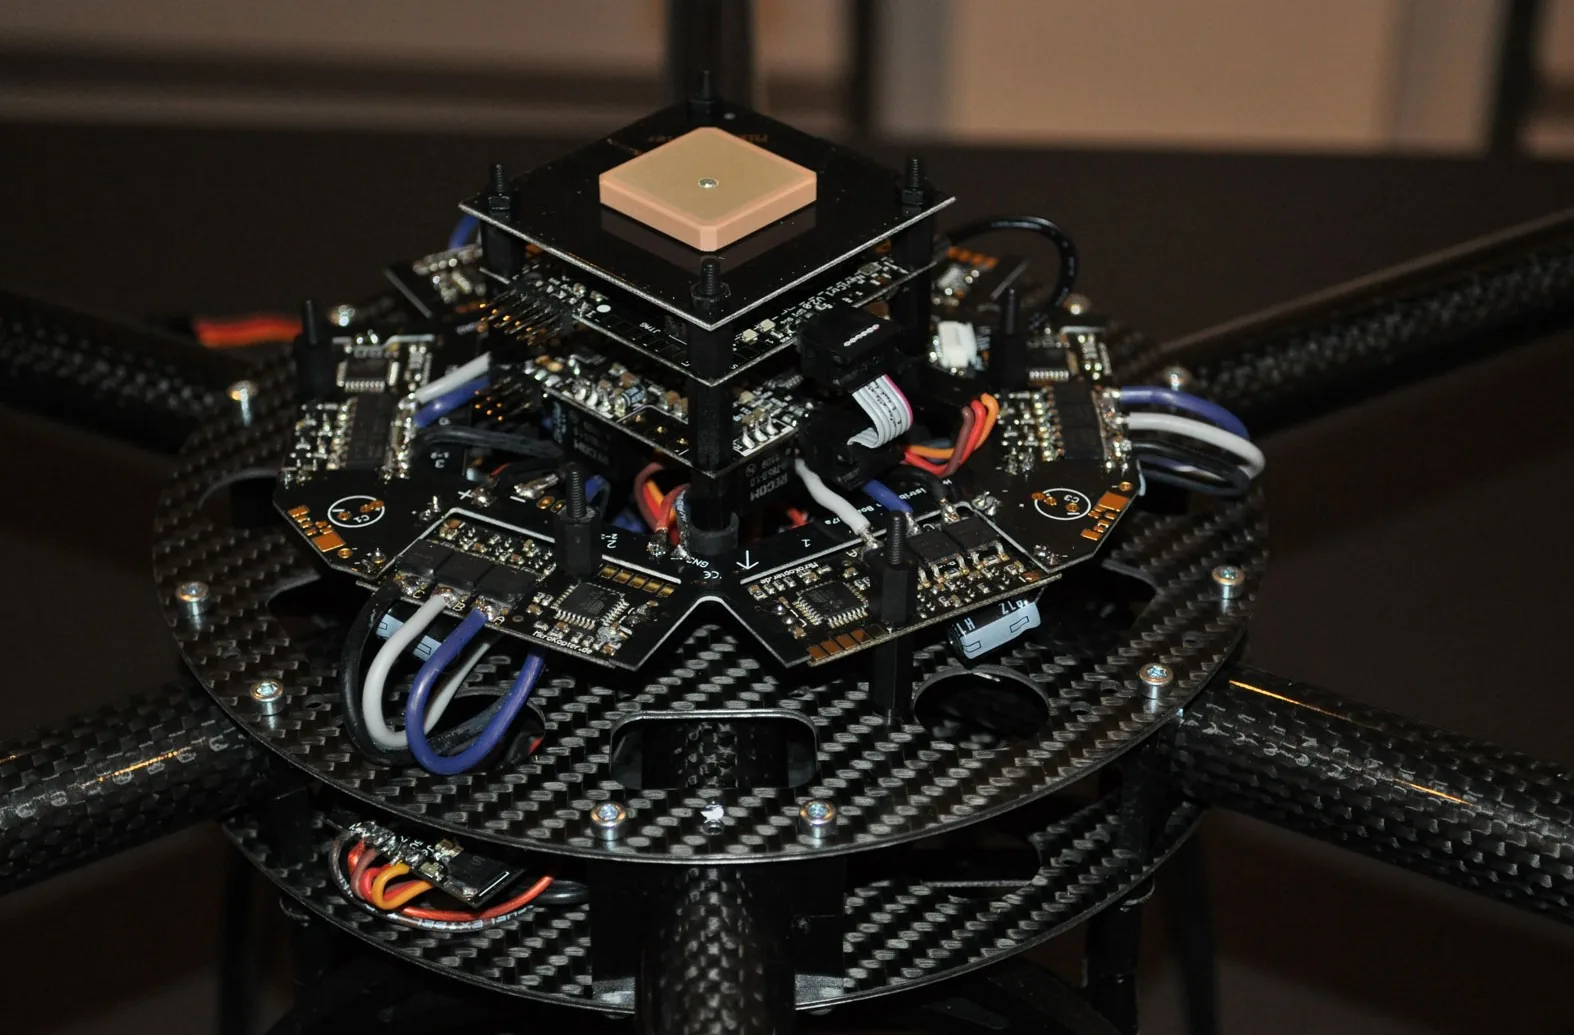
Stacked circuit boards topped by a square GPS antenna, with motor-controller boards and connecting cables arranged around the multicopter frame.Photo: Clicklabs / Wikimedia Commons, CC BY-SA 3.0. Unchanged; full title, source, and license in Sources.

Open Architecture in Unmanned Systems

Understand open architecture in unmanned systems: module interfaces, JAUS and UMAA, integration failures, performance tradeoffs, and component replacement.

CC BY-SA 3.0 Unported, https://creativecommons.org/licenses/by-sa/3.0/. Wikimedia Commons records copyright-holder licensing and VRT ticket 2018081510003395.

Read the analysis
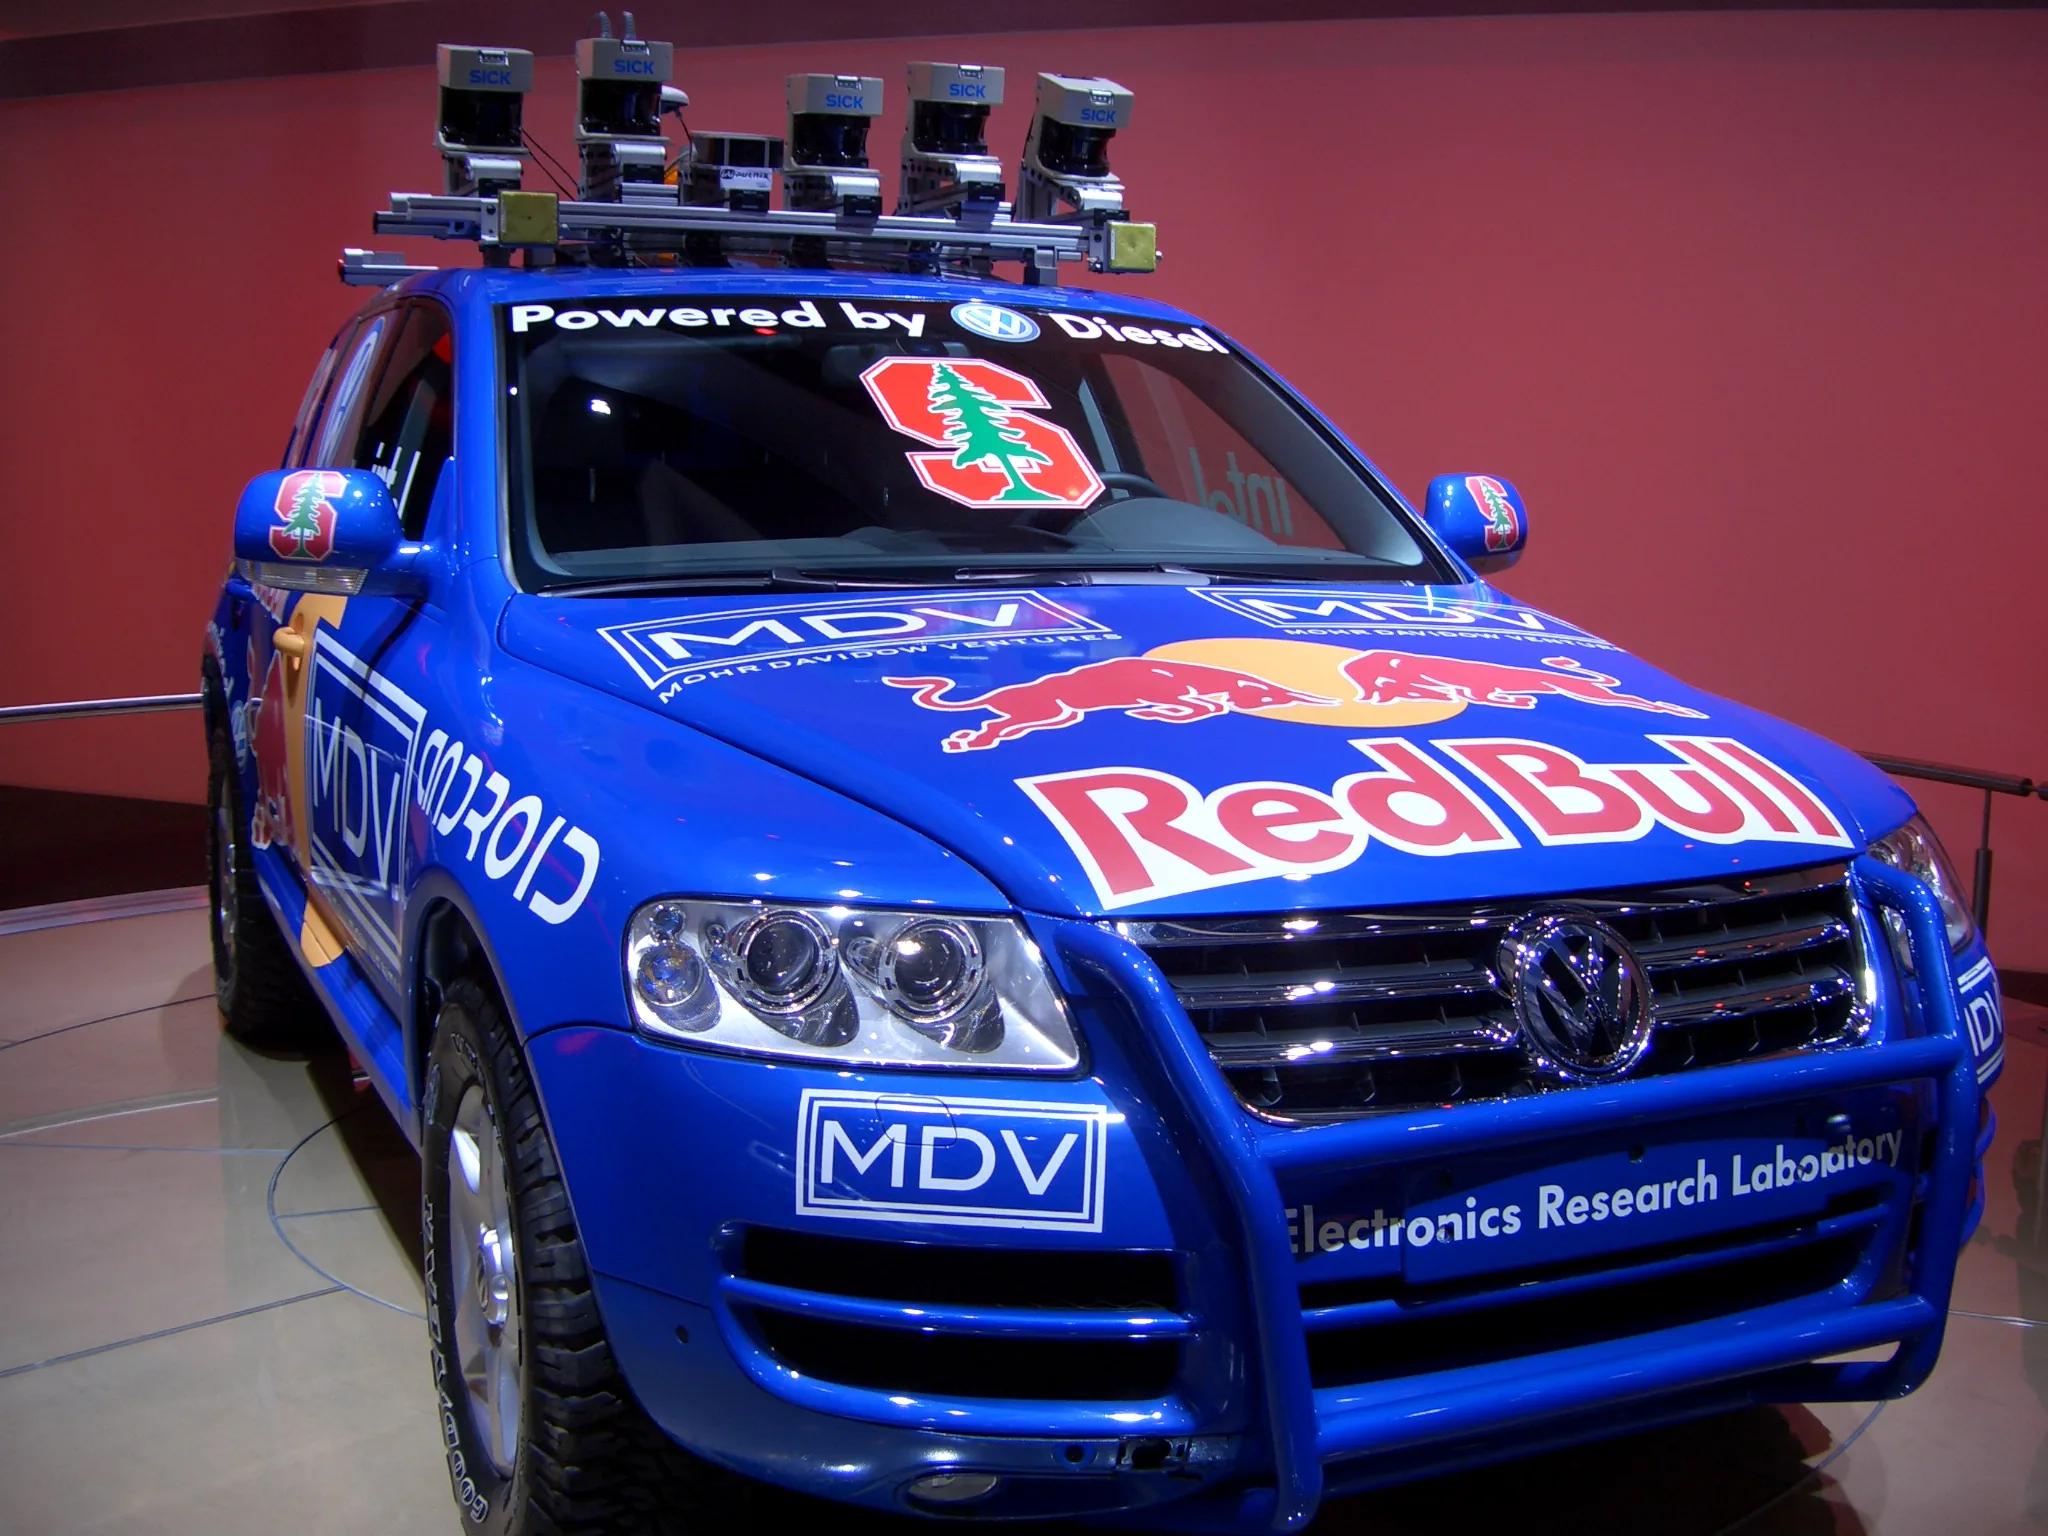
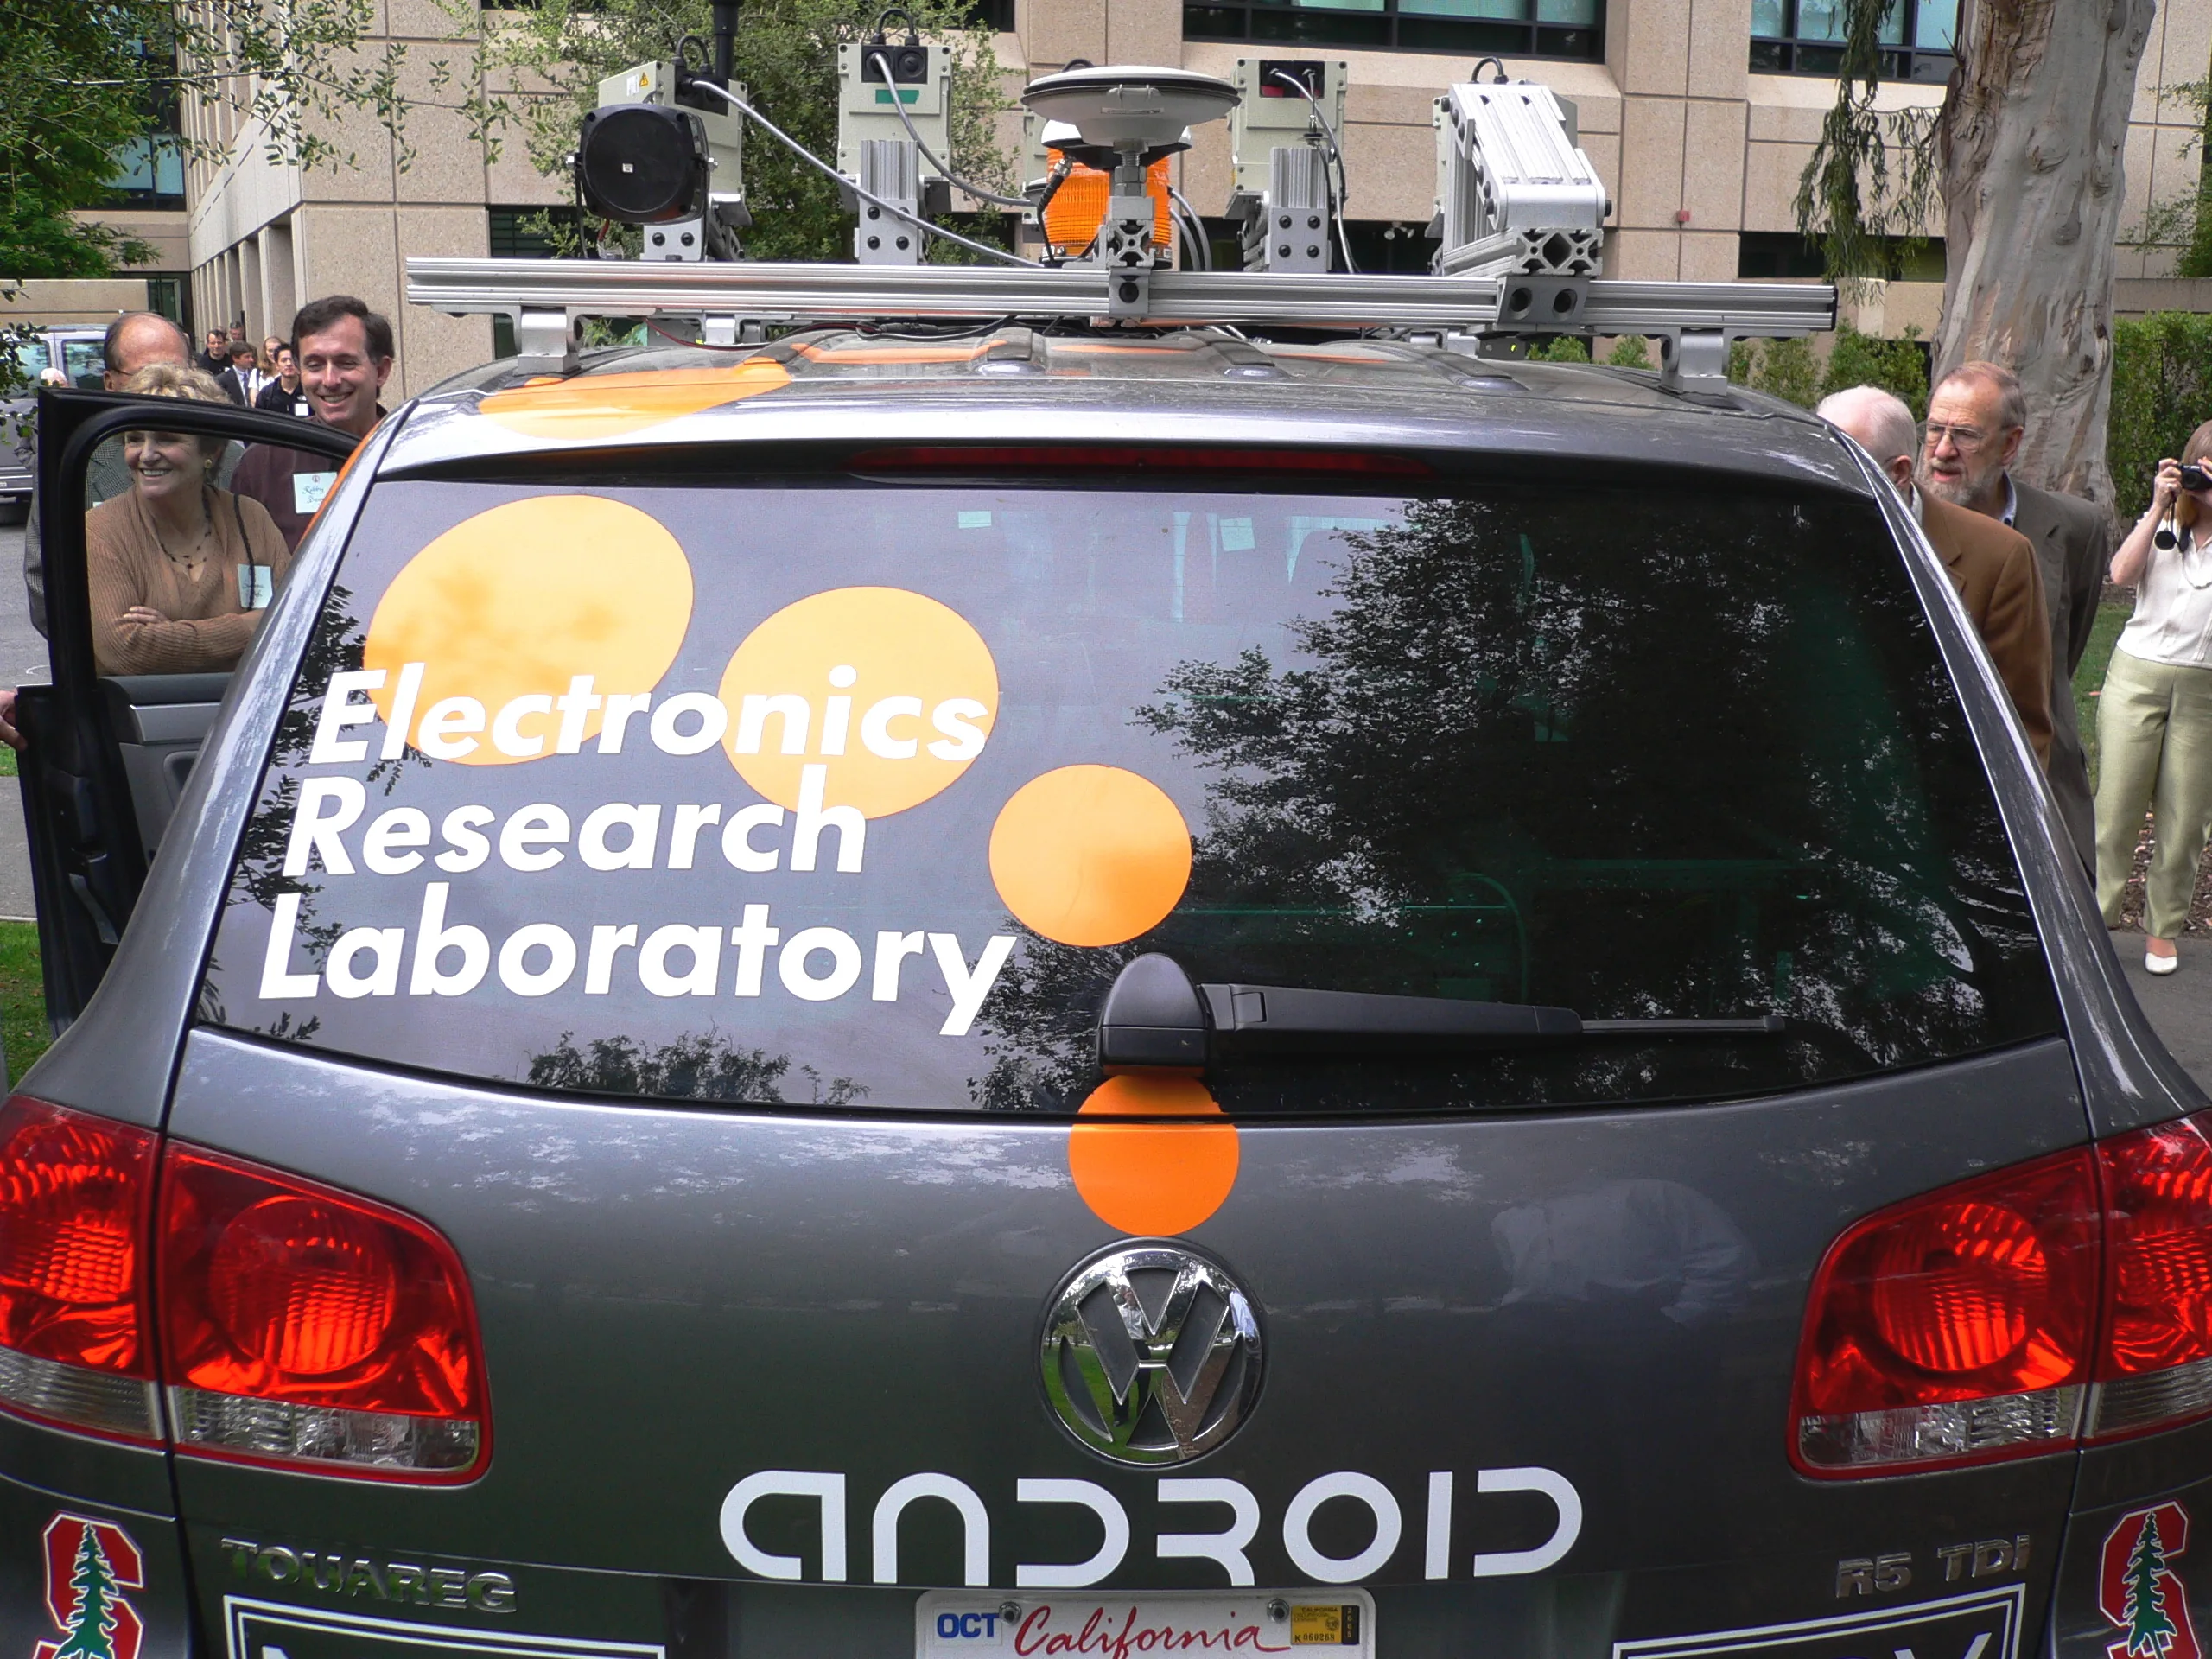
Roof-mounted sensor array on a blue Stanford robotic Volkswagen Touareg displayed indoors.Photo: Global Reactions, via Wikimedia Commons, CC BY 2.0 (https://creativecommons.org/licenses/by/2.0/). Unmodified.

Sensor Fusion for Autonomous Vehicles

How autonomous vehicle sensor fusion works: architecture, sensor interfaces, timing, calibration, uncertainty, failure modes, and practical performance tradeoffs.

CC BY 2.0: https://creativecommons.org/licenses/by/2.0/. Credit Global Reactions; retain source and license links. Unmodified historical photograph; no endorsement.

Read the analysis
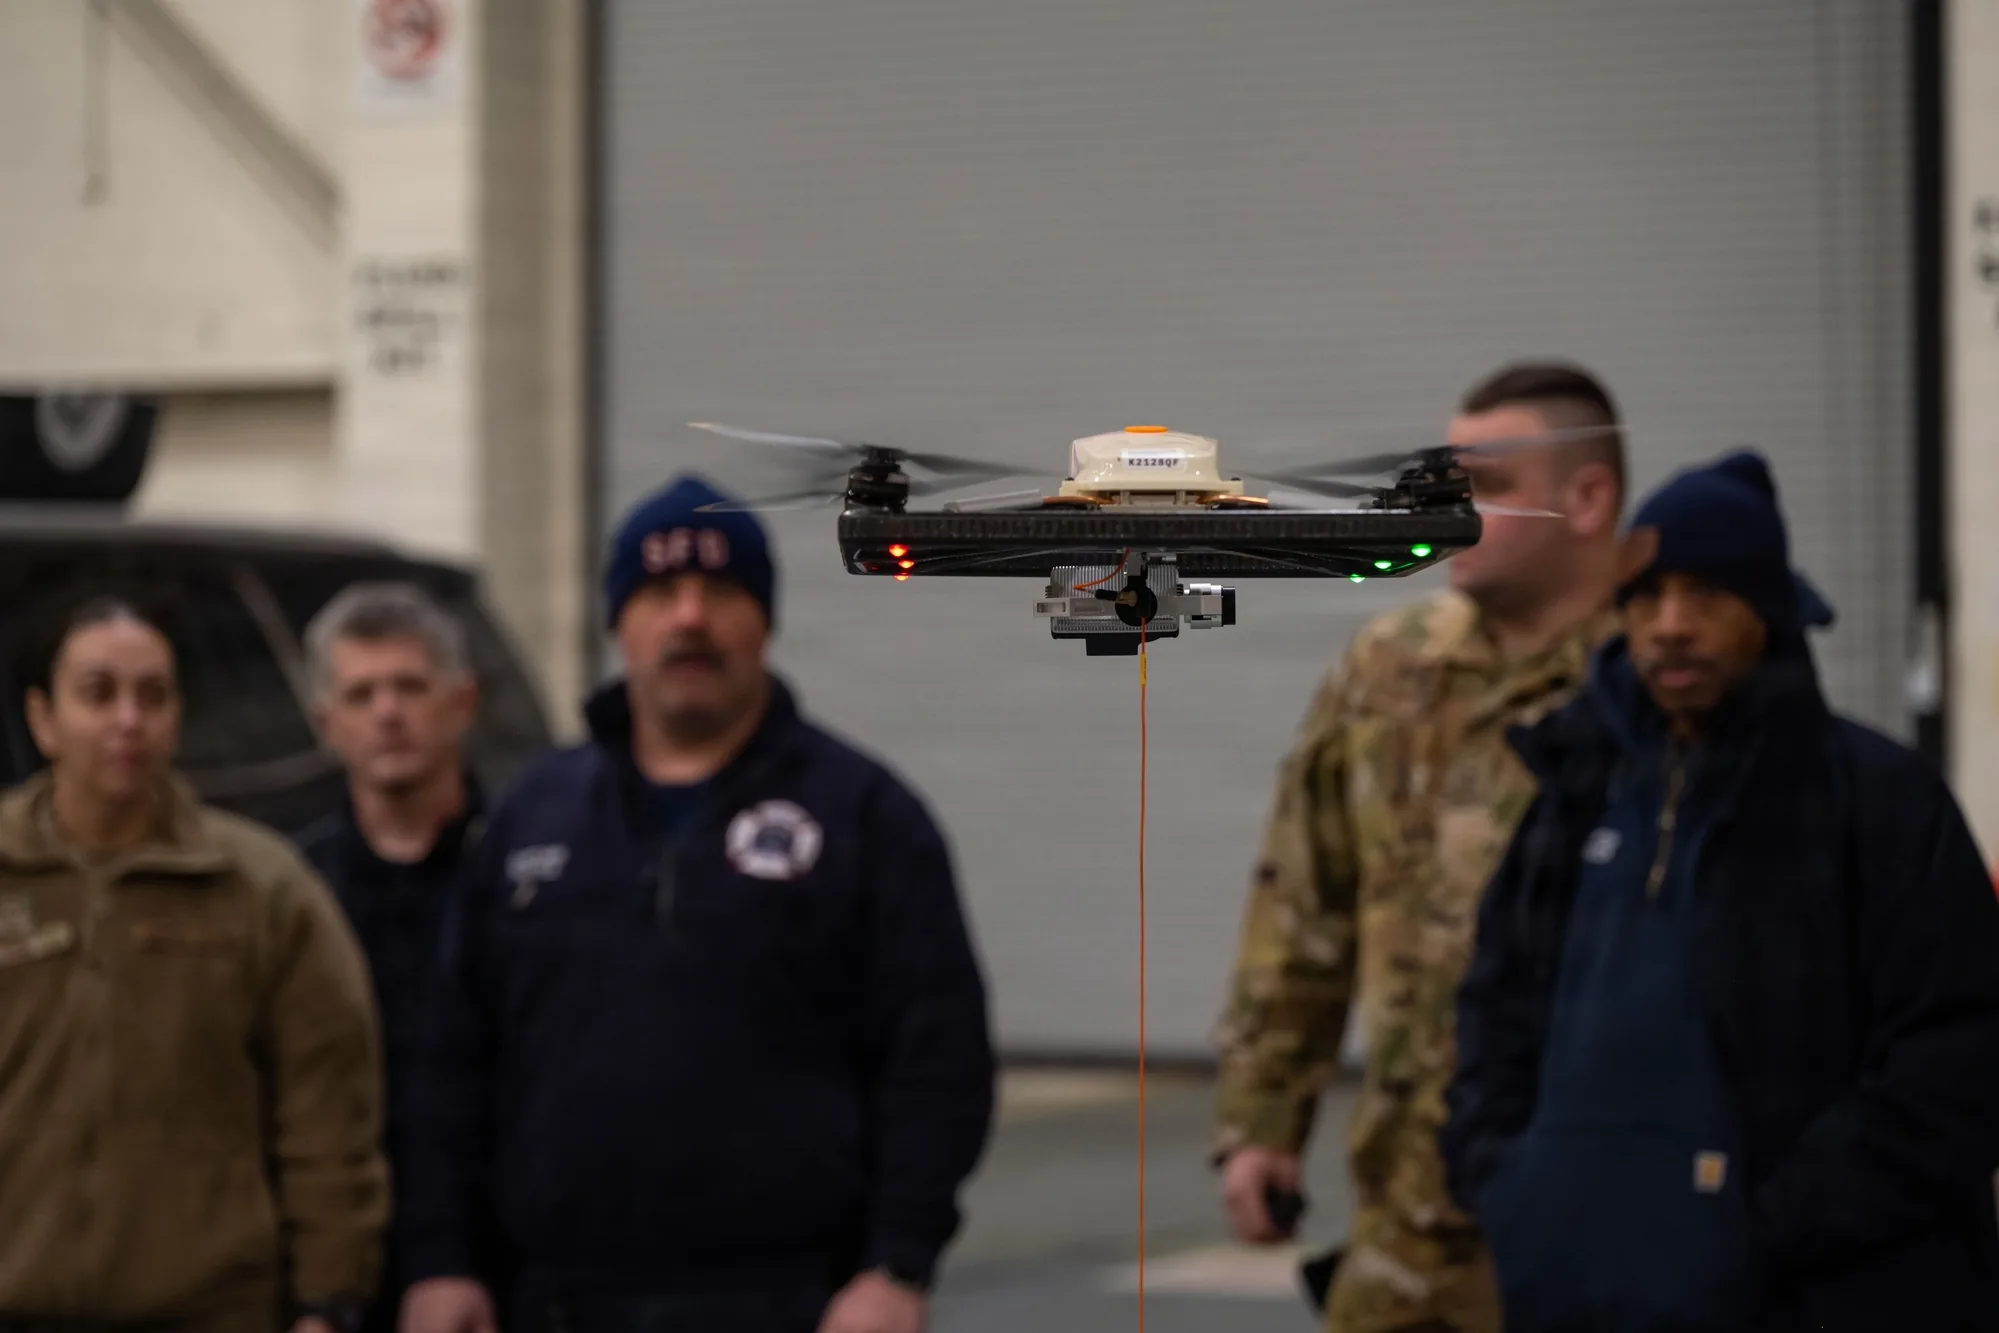
A quadrotor hovers indoors during training, with an orange tether descending beneath it and observers behind it.Photo: Staff Sgt. Sarah Post/U.S. Air National Guard, via DVIDS. Public domain.

Tethered Drones: Power, Data, and Operating Limits

Understand tethered drone power delivery, data interfaces, cable forces, wind and height limits, failure recovery, and mission fit.

DVIDS image 9591668 explicitly marked PUBLIC DOMAIN, VIRIN 260209-Z-SE585-1005. Factual historical editorial reuse under https://www.dvidshub.net/about/copyright with required non-endorsement disclaimer.

Read the analysis
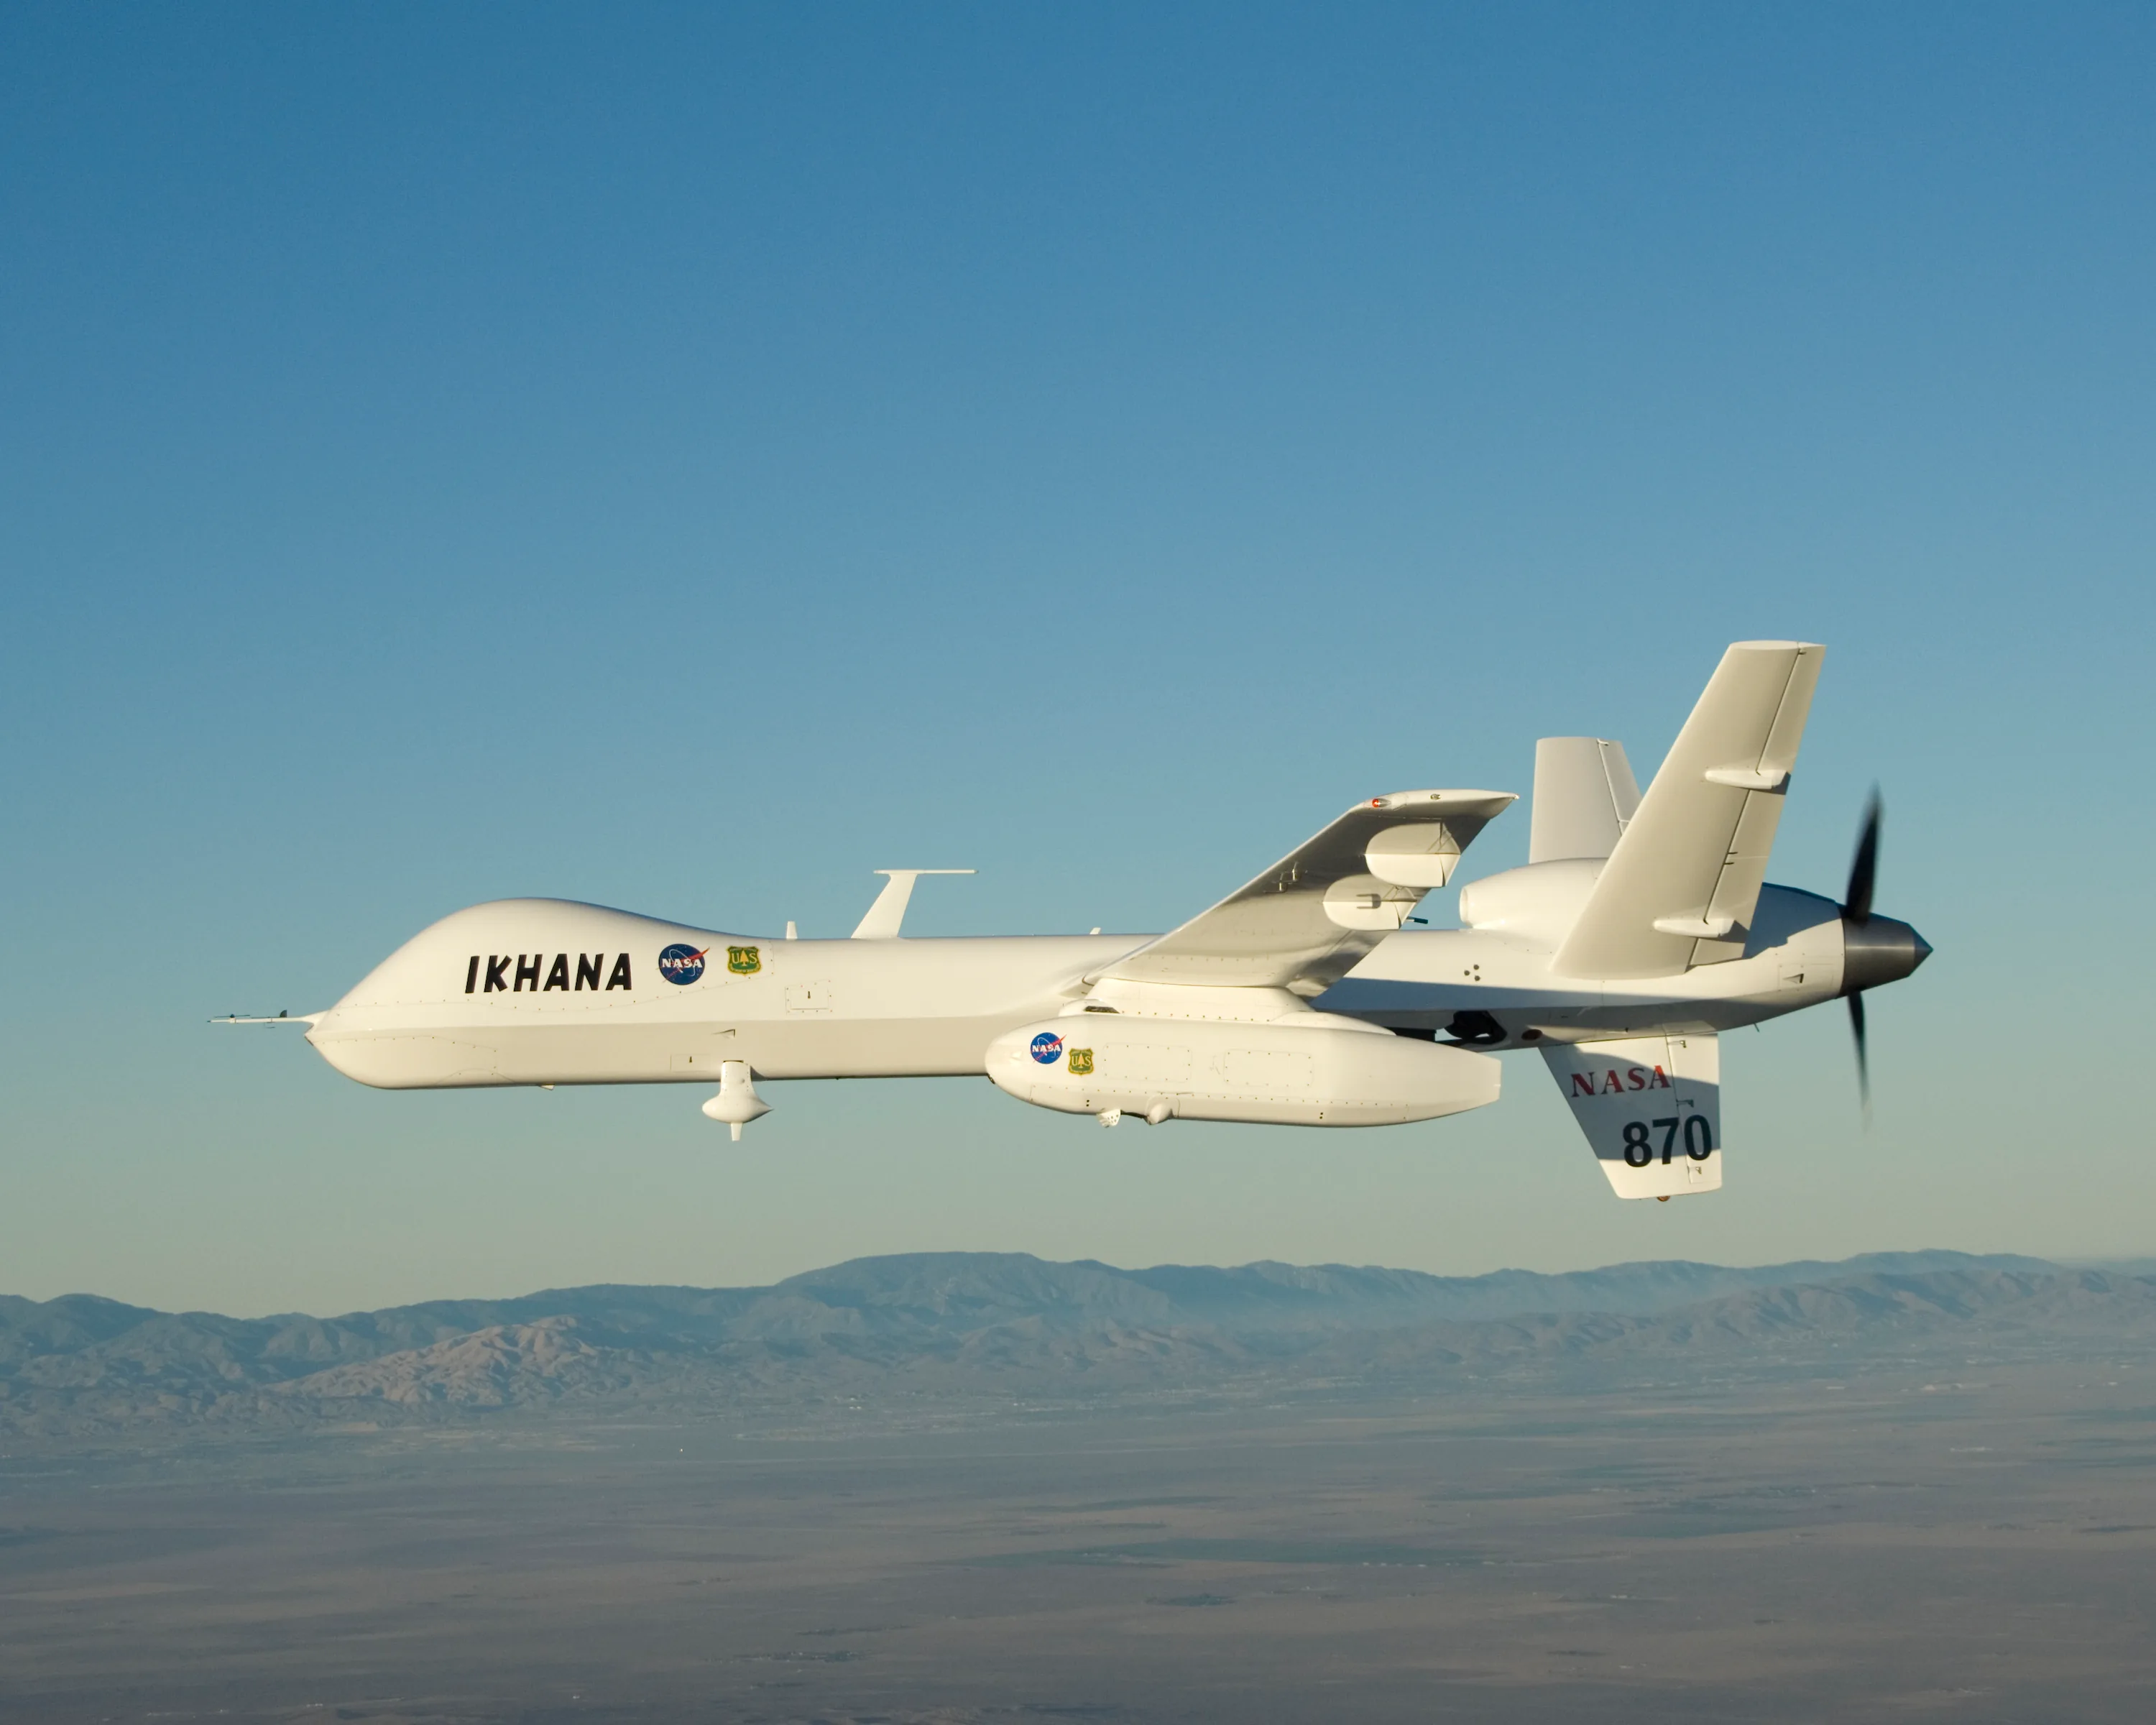
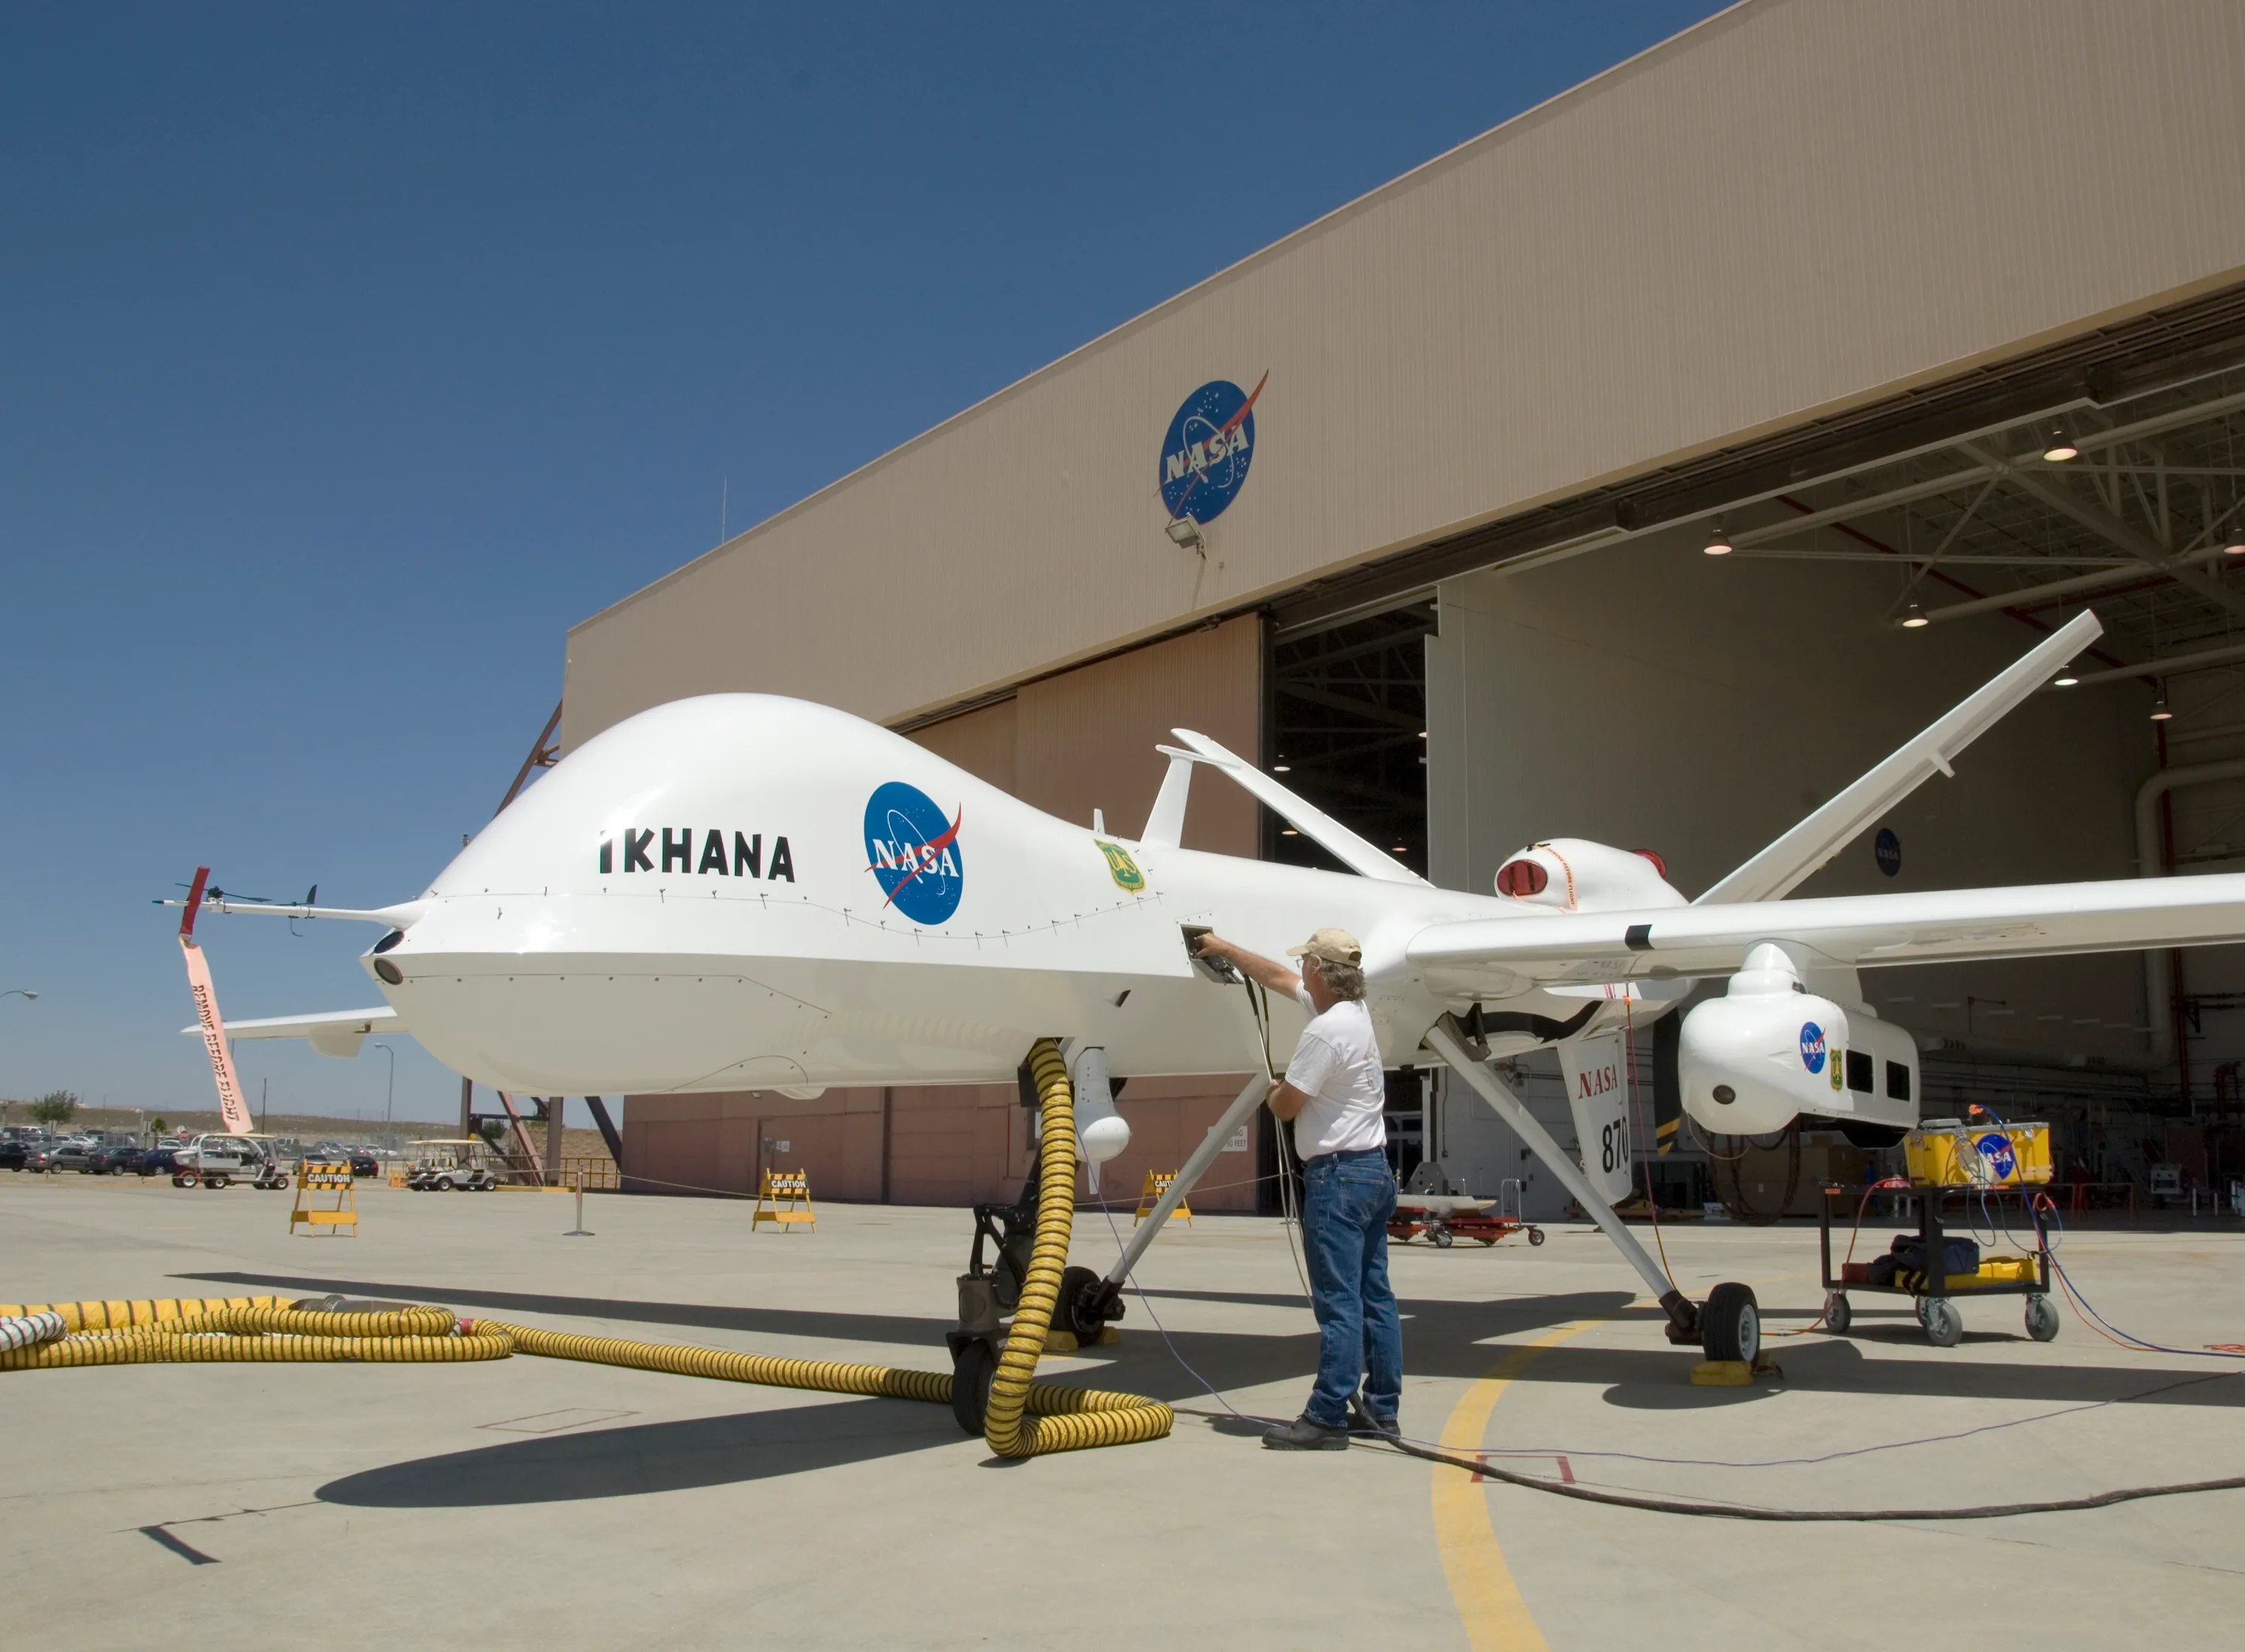
A ground crew member handles connections beside NASA Ikhana outside a hangar, with the aircraft nose, landing gear, and wing-mounted pod visible.Photo: NASA / Tony Landis. Factual editorial use under NASA media usage guidelines.

UAS Airworthiness: Design Assurance and Continued Safety

Understand UAS airworthiness, design assurance, system interfaces, failure modes, and maintenance, with clearly scoped FAA and EASA examples.

NASA public-domain image ED08-0151-02. Non-promotional editorial reuse with NASA / Tony Landis credit under https://www.nasa.gov/nasa-brand-center/images-and-media/; no endorsement.

Read the analysis
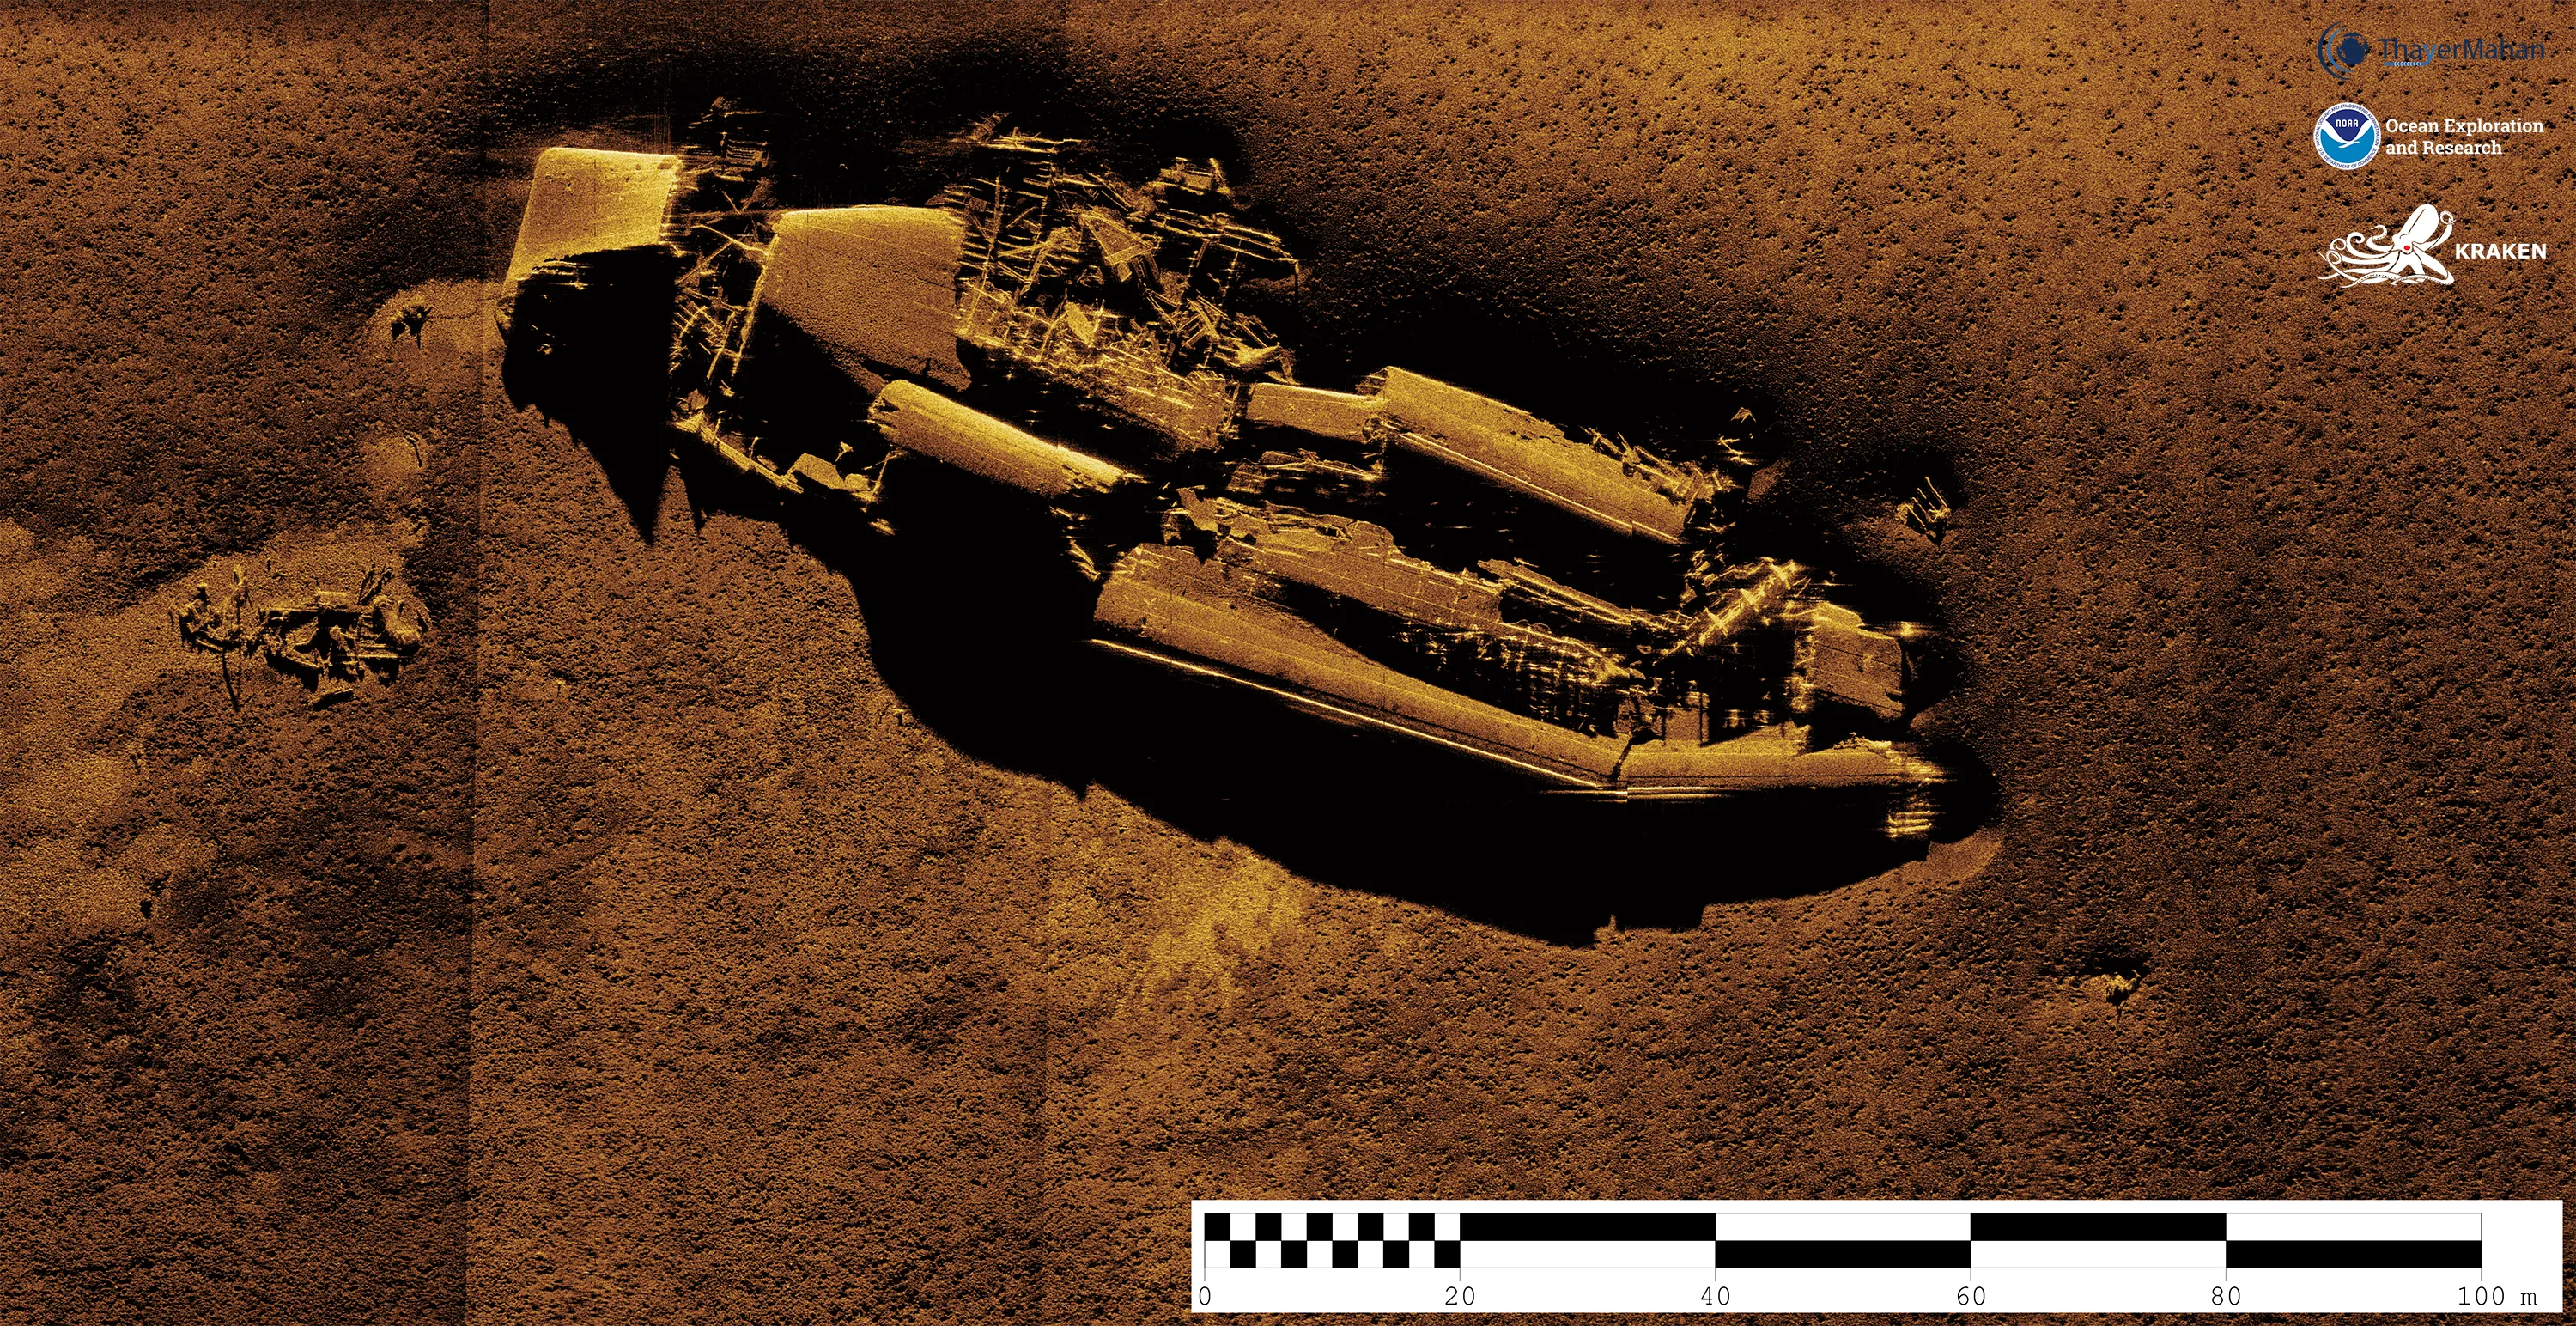
Gold-toned synthetic aperture sonar image showing a broken shipwreck, surrounding seabed, acoustic shadows, and a scale barPhoto: ThayerMahan, Inc., Kraken Robotics, and the NOAA Office of Ocean Exploration and Research

Underwater Sonar Types for Unmanned Vehicles

Compare underwater sonar types for unmanned vehicles: side-scan, multibeam, SAS, forward-looking, and sub-bottom systems, with interfaces and failure modes.

Public domain under https://oceanexplorer.noaa.gov/faqs/; no copyright exception on source page, image, or metadata. Preserve original credit and metadata.

Read the analysis
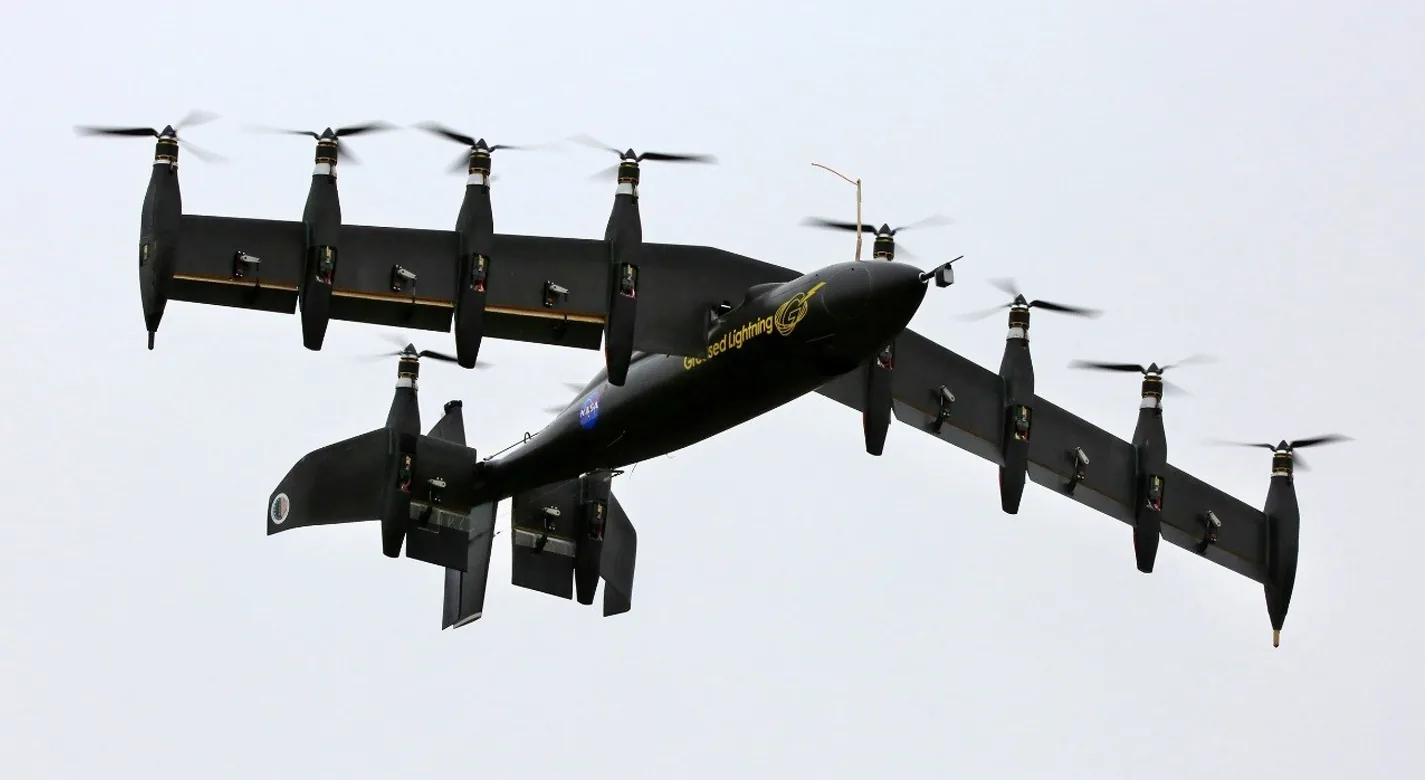
NASA Greased Lightning aircraft in the air, viewed from below with its wing and tail tilted and multiple propellers pointing upward.Photo: NASA. Used for factual editorial illustration under NASA media usage guidelines.

VTOL Fixed-Wing Aircraft: How Transition Flight Works

How VTOL fixed-wing aircraft transfer lift and control during transition, with architecture differences, airspeed limits, failure modes, and landing implications.

NASA permits factual, non-promotional editorial reuse with credit under its media usage guidelines. Source credits NASA and identifies no third-party copyright.

Read the analysis
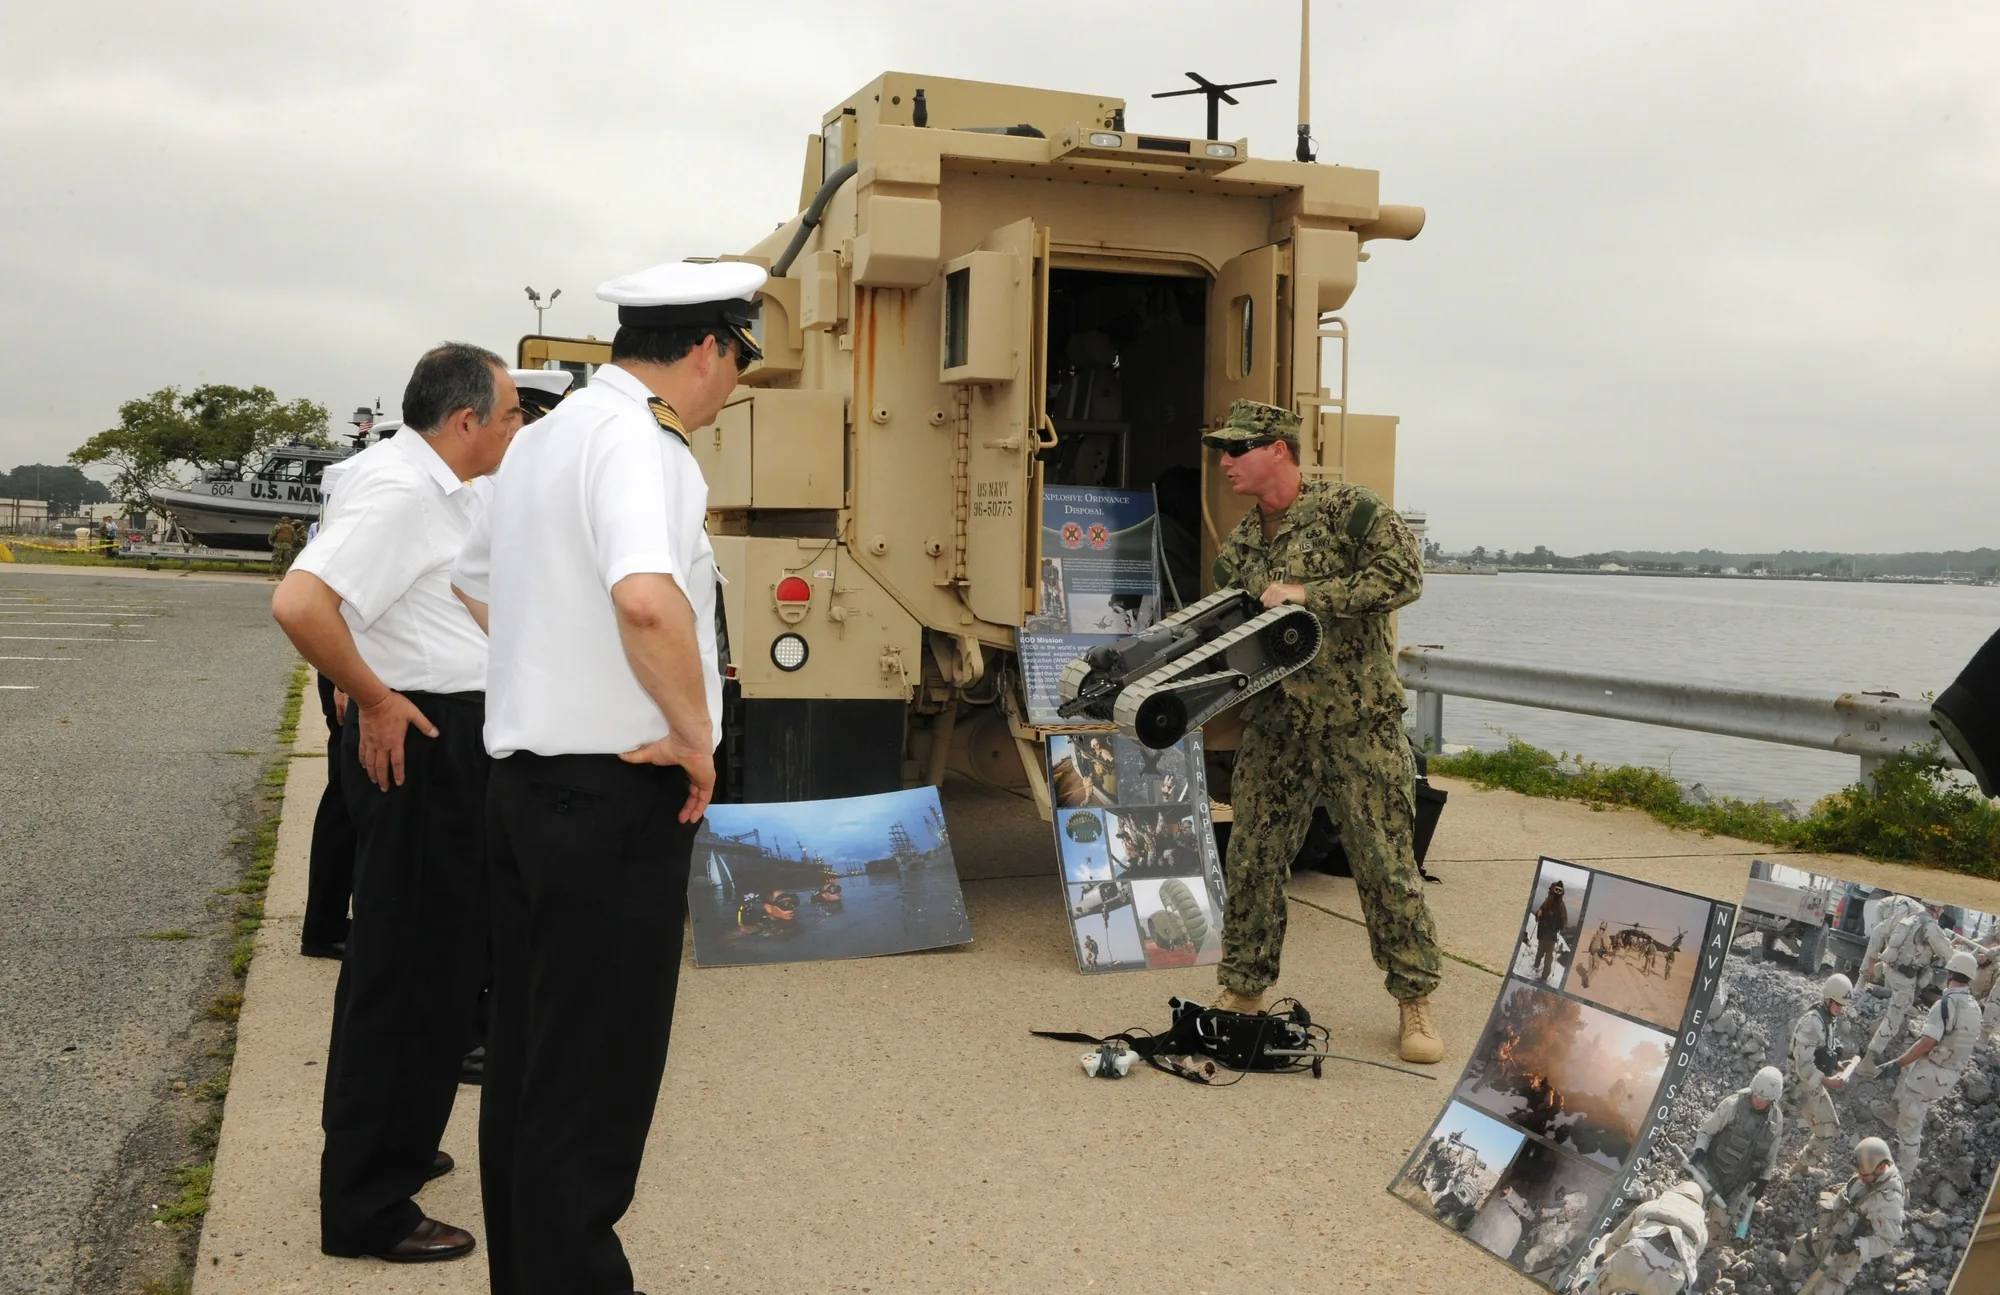
A sailor holds a compact tracked PackBot sideways during an outdoor demonstration, showing its continuous tracks to visitors.Photo: Kay Savarese/U.S. Navy, via DVIDS. Public domain.

Wheeled vs Tracked Unmanned Ground Vehicles

Compare wheeled and tracked UGVs by steering, terrain, energy use, payload integration, maintenance, and mission fit, with practical route-trial criteria.

DVIDS image 642348 explicitly marked PUBLIC DOMAIN; VIRIN 120808-N-ZQ794-096. Factual historical editorial use under https://www.dvidshub.net/about/copyright with required non-endorsement statement.

Read the analysis
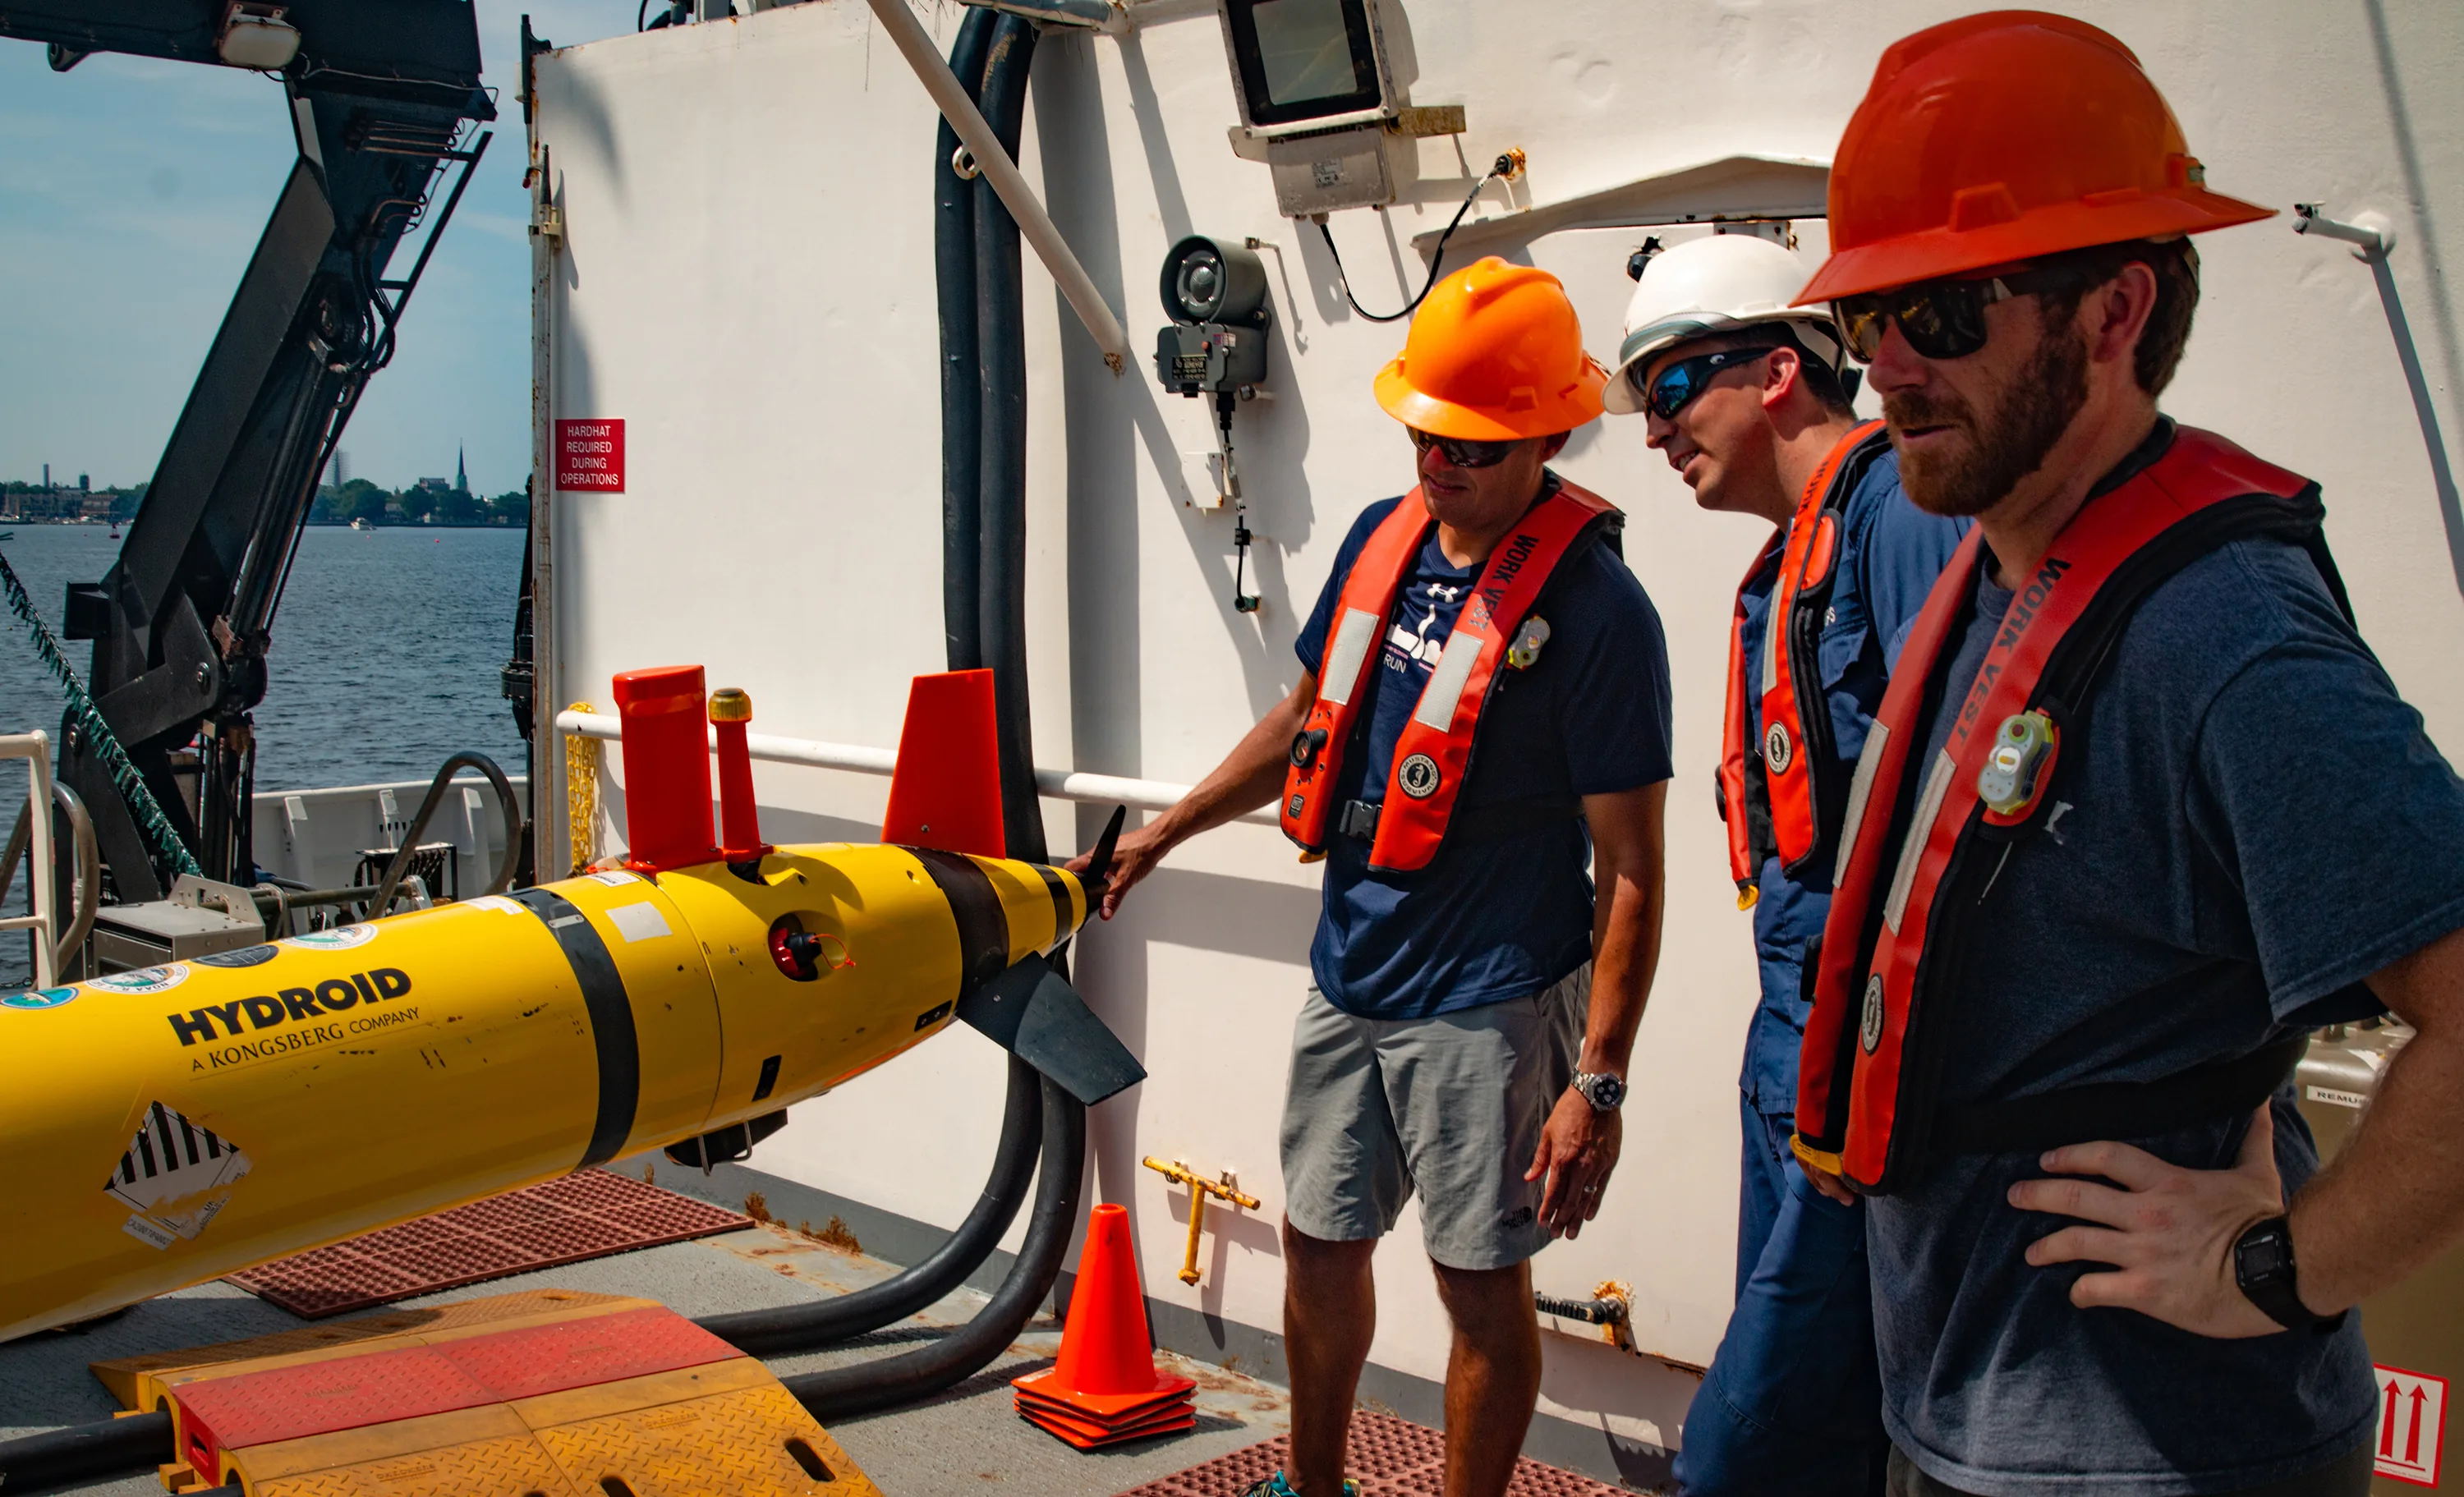
Three crew members in hard hats and flotation vests stand beside a yellow autonomous underwater vehicle on a ship deck.Photo: NOAA Office of Ocean Exploration and Research, 2019 Technology Demonstration. Public domain.
Unmanned Vehicle vs Autonomous Vehicle

Unmanned and autonomous describe different vehicle properties. Compare control architecture, performance, failure behavior, and the missions each approach suits.

Public-domain NOAA photograph; the source credit has no copyright notice. Credit required under https://oceanexplorer.noaa.gov/about/media-kit/ .

Read the analysis